HD-1910-C001
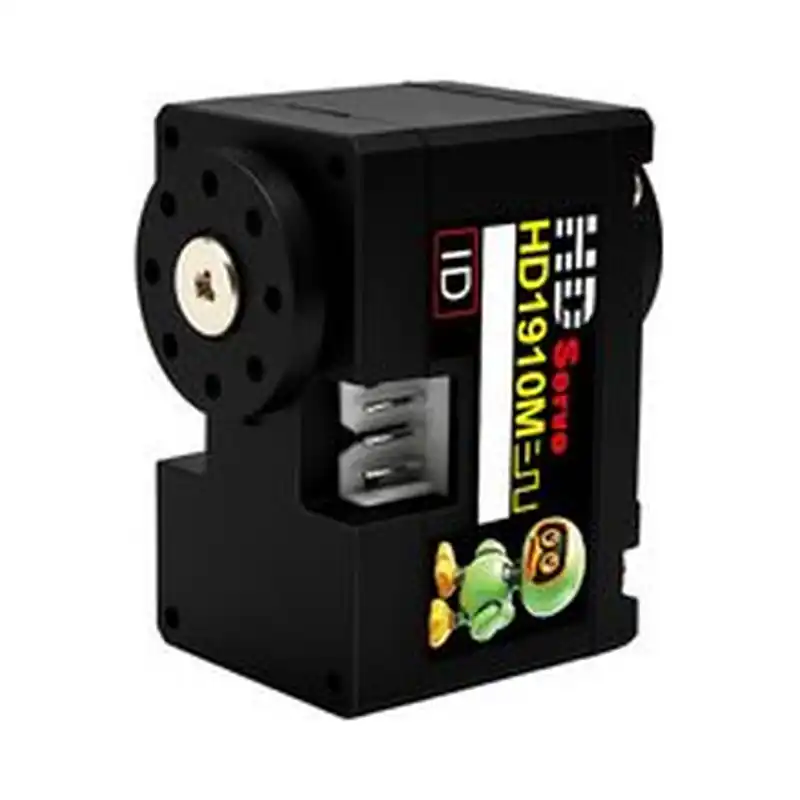
HD-1910-C001 is a compact TTL serial-bus servo for small bipeds and lightweight joints. It combines a coreless motor, metal gears, and a dual-shaft output for Microduck and Open Duck-style robot prototypes.
Back to the HD catalog Product selector
Start your integration
| Your task | Start here | What to check |
|---|---|---|
| Write control software | Software integration | Interface, application layer, read-first bring-up and validation record |
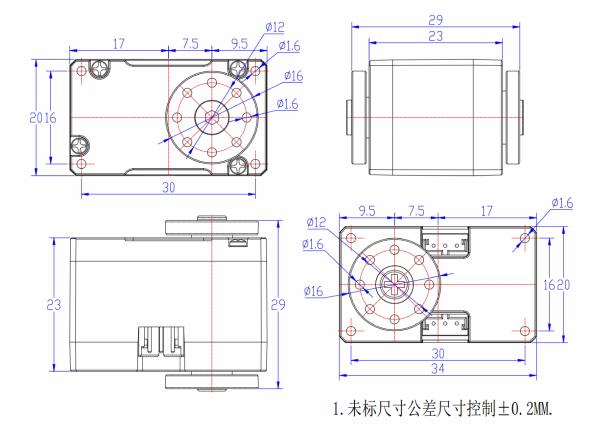
| Design a bracket or joint | Mechanical integration | Drawings, CAD, datum, output shaft and cable clearance |
| Collect engineering files | Resources and status | Available files and outstanding information |
Key specifications
| Item | Value |
|---|---|
| Input voltage | 5–8.4 V |
| Stall torque | 10 kg·cm@6V |
| No-load speed | 0.09 s/60° (110 RPM) |
| Control interface | TTL serial bus |
| Motor | Coreless motor |
| Gear train | Metal gears |
| Output structure | Dual shaft |
| Dimensions | 34 × 20 × 23 mm |
| Weight | 22.5 ± 2 g |
| Standby current | 21 mA |
Selection note
Stall torque is a short-duration limit rather than a continuous operating point. Size power and mechanical margins for simultaneous joint motion, duty cycle, temperature, impact, and peak current.
Suitable applications
- Microduck and Open Duck-style small biped joints
- Robot legs, necks, and lightweight grippers
- Reinforcement-learning and Sim2Real motion experiments
- University robotics labs and embodied-AI prototypes
- Multi-joint mechanisms with tight space and mass limits
Integration notes
- Use a stable 5–8.4 V supply. A fully charged 2S lithium pack is already at the 8.4 V upper limit.
- Assign unique IDs on a shared bus and size the supply for simultaneous start-up and obstructed motion.
- Verify the dual-shaft geometry, horn projection, mounting holes, and joint zero before installation. Mechanical parts designed for another servo are rarely direct replacements.
- Begin with slow, small, unloaded movements before increasing travel.
- Use the formal HD-1910-C001 memory table and installed firmware for register addresses, modes, and units. Do not copy another family's table.
Open Duck project note
HD-1910-C001 is intended for lightweight Microduck/Open Duck-style bipeds. A servo change still requires checking mechanics, power, bus protocol, joint zero, controller gains, and the learned policy. It is not a drop-in replacement for another brand's servo or STS3215.
Public project reference: Pollen Robotics Microduck
Official model specifications
FEETECH official product page · Checked 2026-10-02. The complete model on the page is HD-1910-C001.
| Parameter | Manufacturer specification |
|---|---|
| Model | HD-1910-C001 |
| Storage Temperature Range | -30℃~80℃ |
| Operating Temperature Range | -20℃~60℃ |
| Temperature Range | 25℃ ±5℃ |
| Humidity Range | 65%±10% |
| Size | A: 34mm B: 20mm C: 23mm |
| Weight | 21±2g |
| Gear type | Metal Gear |
| Limit angle | No limit |
| Bearing | 滚珠轴承 Ball bearings |
| Horn gear spline | 25T/OD4.95mm |
| Gear Ratio | 1/320 |
| Back Lash | ≦0.5° |
| Case | PA66+GF43% |
| Connector wire | 15± 0.5cm |
| Motor | Coreless Motor |
| Rated Input Voltage | 4V-8.4V |
| No load speed | 0.137sec/60 °(73RPM)@4.8V |
| Runnig current(at no load) | ≤160mA@4.8V |
| Peak stall torque | 9kg.cm@4.8V |
| Stall current | 1.2A@4.8V |
| Rated Load | 2.2kg. cm@4.8V |
| Rated current | 500mA@4.8V |
| KT | 7.5kg.cm/A |
| Operating Modes | Mode 0: Angle servo mode (default mode, absolute position controllable from 0-360 degrees) |
| Multi-Loop Mode | Control of positive and negative 7 turns at the highest accuracy, but the umber of power failure turns is not saved (the resolution can be expanded, and the number of turns can be doubled) |
| Constant force output | Set the output torque value, the servo can maintain this torque (input the target torque value corresponding to address 44, the servo can maintain this torque) |
| Command signal | Digital Packet |
| Protocol Type | Half Duplex Asynchronous Serial Communication |
| ID | 0-253 |
| Communication Speed | 38400bps ~ 1 Mbps |
| Control Algorithm | PID |
| Neutral Position | 2048 |
| Running degree | 360° (when 0~4095) |
| Resolution [deg/pulse] | 0.088°(360°/4096) |
| Rotating Direction | Clockwise(0→4095) |
| Feedback | Load, Position,Speed, Input Voltage,Current,Temperature |
Resources and document status
Local attachments are included in the model package; PDF specifications link to the manufacturer and are not bundled offline. Missing resources are not yet supplied; family guides do not verify model-specific settings.
| Resource | Status / file | Revision |
|---|---|---|
| Model datasheet | Not supplied | — |
| Connector and pinout | Not supplied | — |
| Model memory table / firmware notes | Not supplied | — |
| 2D mounting drawing | drawing.webp | — |
| STEP / 3D model | HD-1910-C001-20260902.stp | — |
| Model-tested example | Not supplied | — |
| Raw test data | Not supplied | — |
| Test record and conditions | Not supplied | — |
Package manifest · Request missing resources
For an offline ZIP with both languages and available attachments, see product-package export.
Request resources or report an issue
Use your existing FEETECH technical-support contact and include the full label/model suffix, firmware version (if known), and the document revision you are using.
- Software: controller/OS, SDK version or commit, adapter/interface, supply voltage, confirmed ID/baud rate (bus models only), minimal reproduction and logs.
- Mechanics: drawing/CAD revision, marked dimensions, required travel, horn/bracket, load and lever arm, duty cycle, and the point of interference.
- Missing files: name the exact item in the resource table (for example, this model's STEP and a dimensioned mounting drawing).
This package currently provides a specification summary and integration checklists. File availability does not imply that your firmware, load case or assembly has been validated.