Get started
Confirm the complete physical model and its document status first, then choose the control path; whether you are about to integrate software or design mechanics, start from the entries below.
If you already have the hardware, the model printed on the label is the model used on this site (written as "series-code-sequence", e.g. ST-3215-C001) — type it into the site search at the top right to jump to its model page. If it does not match (some older PWM names carry no -C00x), look it up by prefix in Series and Interfaces, or filter it with the selector in Product Selection.
Find my model I am designing mechanics
Choose a control path
Four things must match: the interface, the debug board or controller, the supply and the signal source. Check them in this order — "servo interface → debug board or controller → supply → signal source (host software, SDK, MCU PWM output or RC receiver)" — and look up the documents as soon as any step fails to match.
Both routes — the bus (TTL / RS-485 / CAN) and PWM — go through Power and Wiring first (bill of materials → interface categorisation → wiring topology → supply capacity → bus rules → pre-power checks). Once the pre-power checks pass, follow the interface you confirmed into the route page below.
| Interface confirmed by the model documents | Route page | First completion check |
|---|---|---|
| TTL / RS-485 bus | Bus servo setup | One servo's identity and read-only communication confirmed, before a small motion |
| PWM | PWM servo setup | Period, pulse width and pinout confirmed, before neutral/stop and small-response checks |
| CAN bus | Bus servo setup | Baud rate and node address confirmed, before node status and command response |
| Interface or complete model unknown | Series and Interfaces | Obtain the documents matching the physical suffix; do not probe the wiring or send commands yet |
How to read this group
| Page | Covers | Read it when |
|---|---|---|
| Power and Wiring | Bill of materials, interface categorisation, wiring topology, supply capacity, bus rules, pre-power checks | Shared by both routes — for parts, wiring and pre-power |
| Bus servo setup | Prepare → power up → establish communication → record ID and baud rate | Your interface is TTL / RS-485 / CAN |
| PWM servo setup | Information before power-up → where the signal comes from → first-motion validation → how the program drives it → record (all on this page) | Your interface is PWM |
| First Motion | One controlled motion and the stop method after communication is established | A bus servo's communication is stable |
Common servo interfaces
This section lists only the common interface types and harnesses; the actual interface shape, pinout and wire order follow the physical unit and the supplied drawings. Start from the model prefix to determine the family and control interface (complete table in Series and Interfaces):
SC-/ST-/HL-/HD-and similar are TTL busSM-is RS-485 bus (including MODBUS-RTU models)FU-is CAN busFT-/FB-/FS-/FR-/FI-are PWM
Cross-check against the harness as well — 3-wire TTL and PWM cannot be told apart by wire count alone.
TTL bus (UART)
TTL is the electrical layer and UART the frame format; what this site and most vendors call a "TTL bus servo" runs UART frames, so the two are one and the same entry. There are four common pinouts below — identical pin order, different connector styles only; follow the physical unit and the supplied drawings.
Figure 1 (TTL bus · Conversion): UART to a TTL single bus — TX and RX are time-multiplexed onto the one Signal wire (half duplex), with GND common; V+ is the servo power, supplied by an external supply per model (6 V / 7.4 V / 12 V…), not the host's 3.3 / 5 V; the join is made by the transceiver circuit inside the debug board.
Advanced: level-shifting schematics between an MCU UART and the bus
The Signal in Figure 1 is not a level an MCU UART pin can drive directly: a TTL single bus is half duplex, so the same wire both sends and receives, while RS-485 is a differential bus (A, B). The schematics are below:
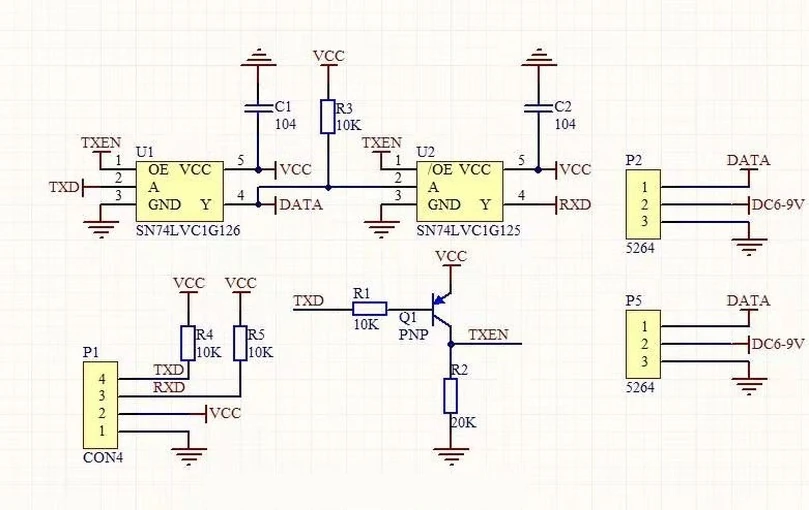
TTL single-bus conversion: the transmit direction drives the DATA line through a 74LVC1G126 buffer, the receive direction reads back through a 74LVC1G125, and TXEN interlocks the two directions; the VCC level follows the MCU UART level, and the lines that come out are DATA, power and GND.
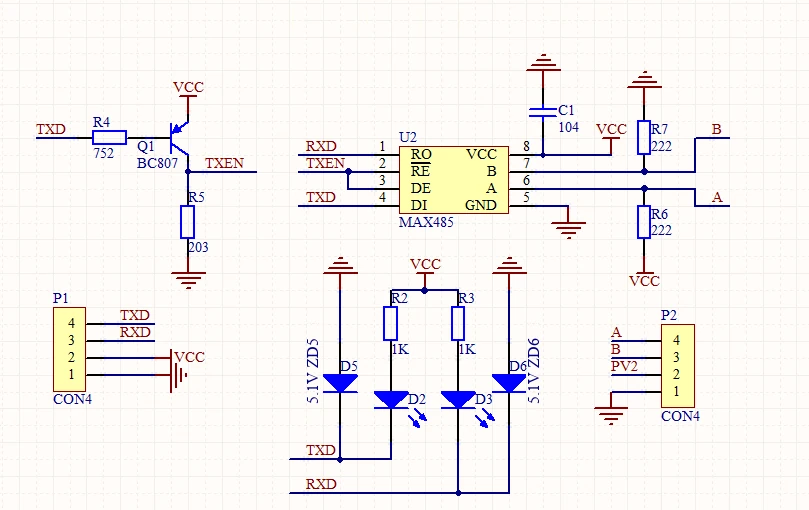
RS-485 conversion: a MAX485 converts the MCU UART's TXD/RXD into the differential pair A / B, TXEN controls the direction, and A / B / GND go to the bus.
If you would rather not build the circuit yourself, use a ready-made debug board (see Debug Boards and Adapters); CAN needs a dedicated transceiver and termination resistors (see Bus servo setup) and is outside the two schematics above.
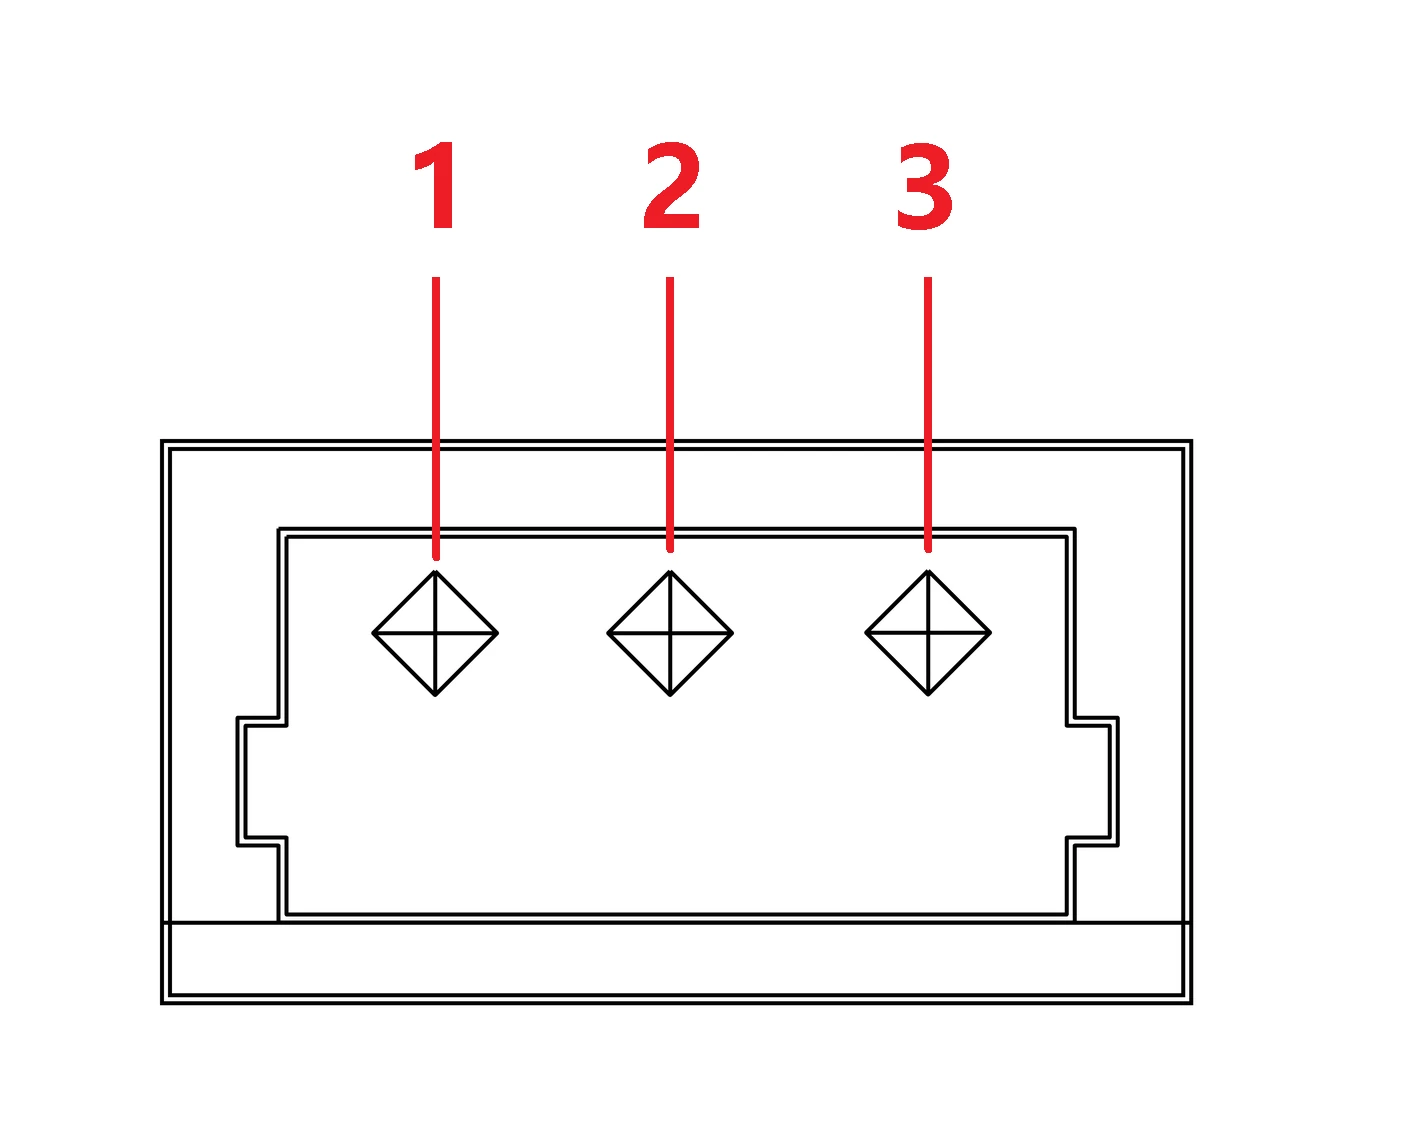
Pinout 1: SH 1.25 terminal
 |
|
A 3-pin micro connector with a latch (SH 1.25, 1.25 mm pitch family). Wire colours and applicable models follow the physical unit and the supplied drawings.
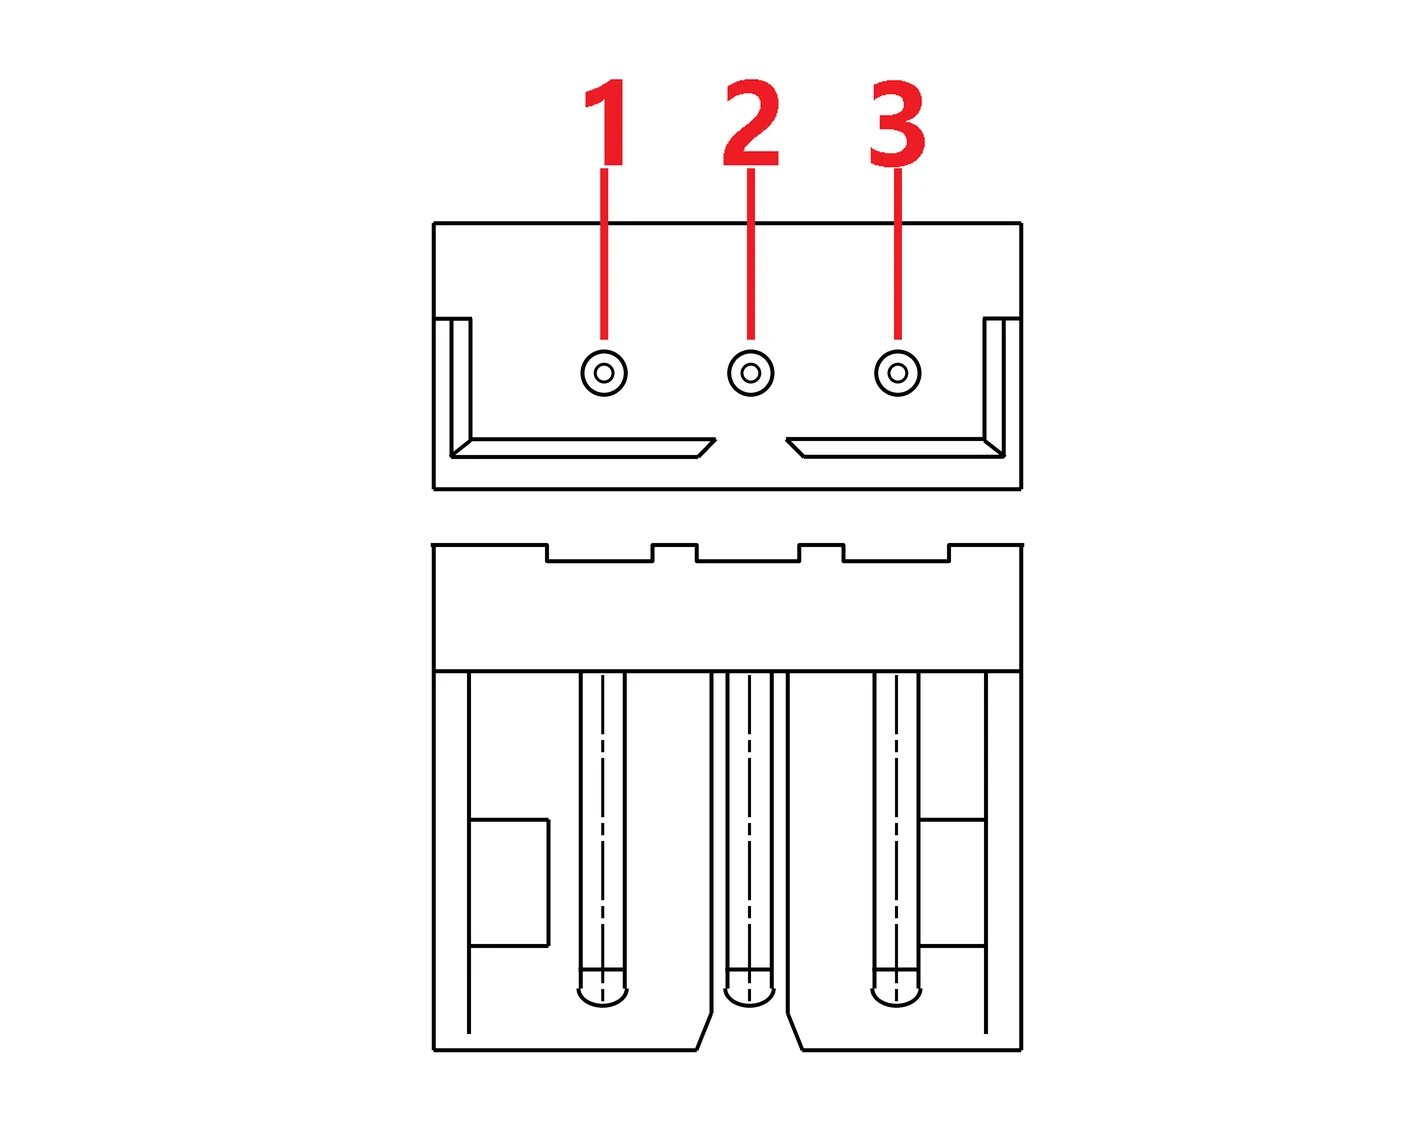
Pinout 2: AMP-3P terminal
 |
|
A white 3-pin connector (AMP-3P, 2.0 mm pitch family). It shares the 2.0 mm pitch with pinout 3 but belongs to a different terminal family, so the two must not be interchanged. Wire colours and applicable models follow the physical unit and the supplied drawings.
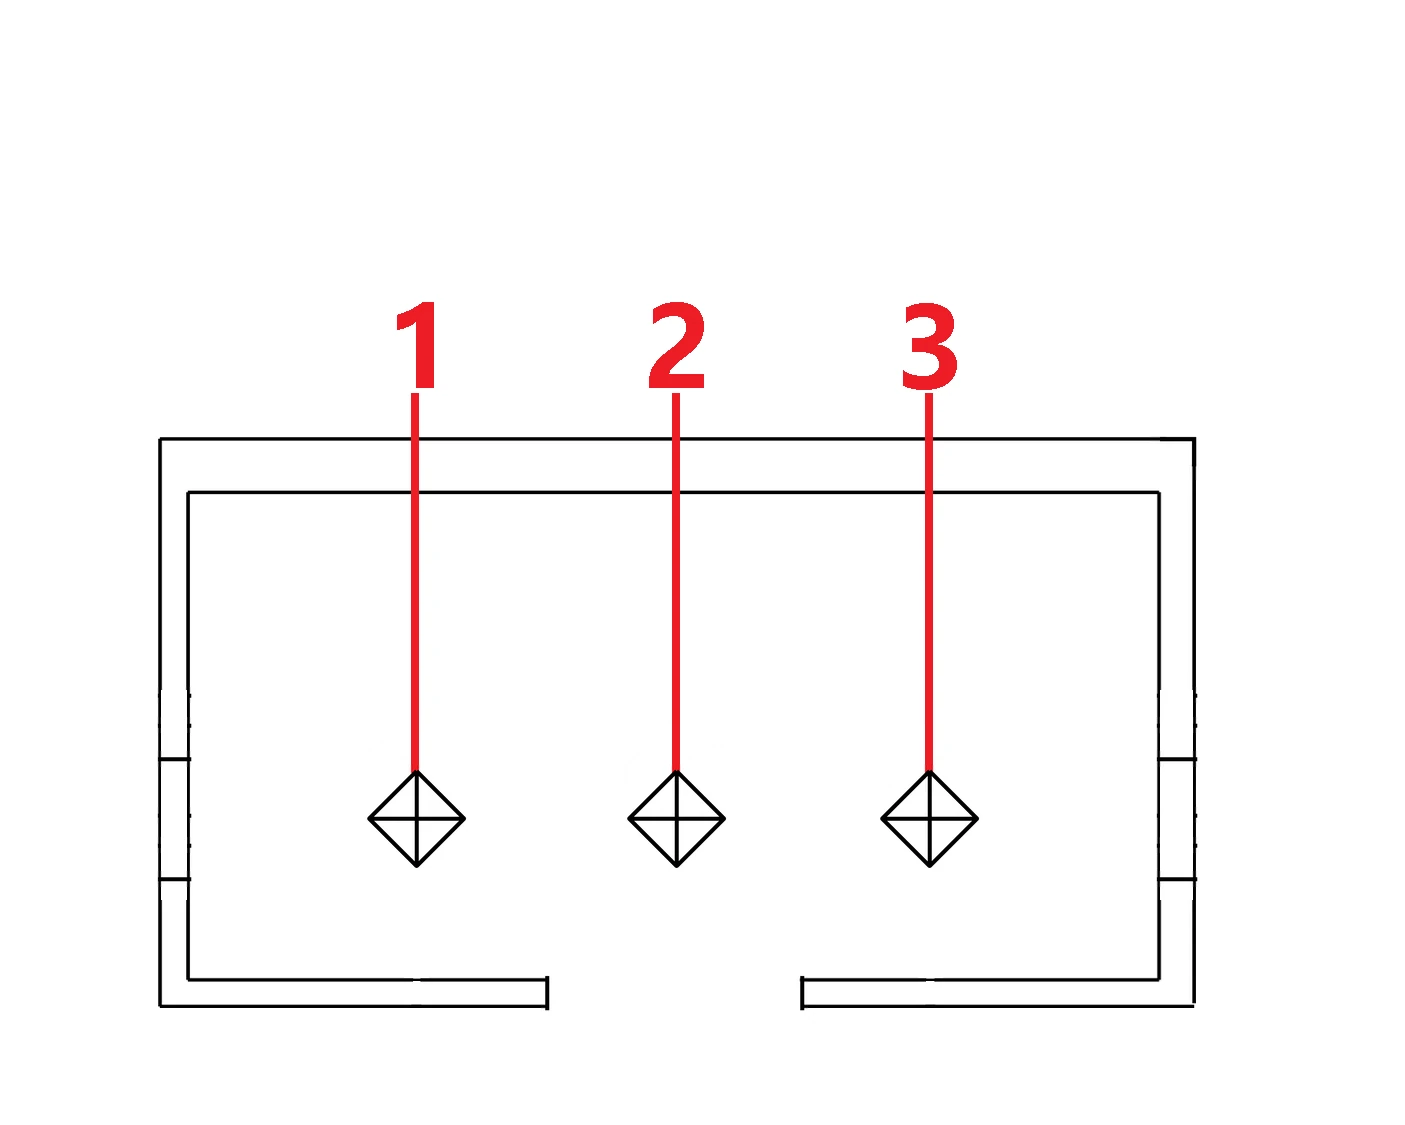
Pinout 3: PH3AW-2.0 terminal
 |
|
A white 3-pin connector (PH3AW-2.0, PH family, 2.0 mm pitch). It shares the 2.0 mm pitch with pinout 2 but belongs to a different terminal family, so the two must not be interchanged. Wire colours and applicable models follow the physical unit and the supplied drawings.
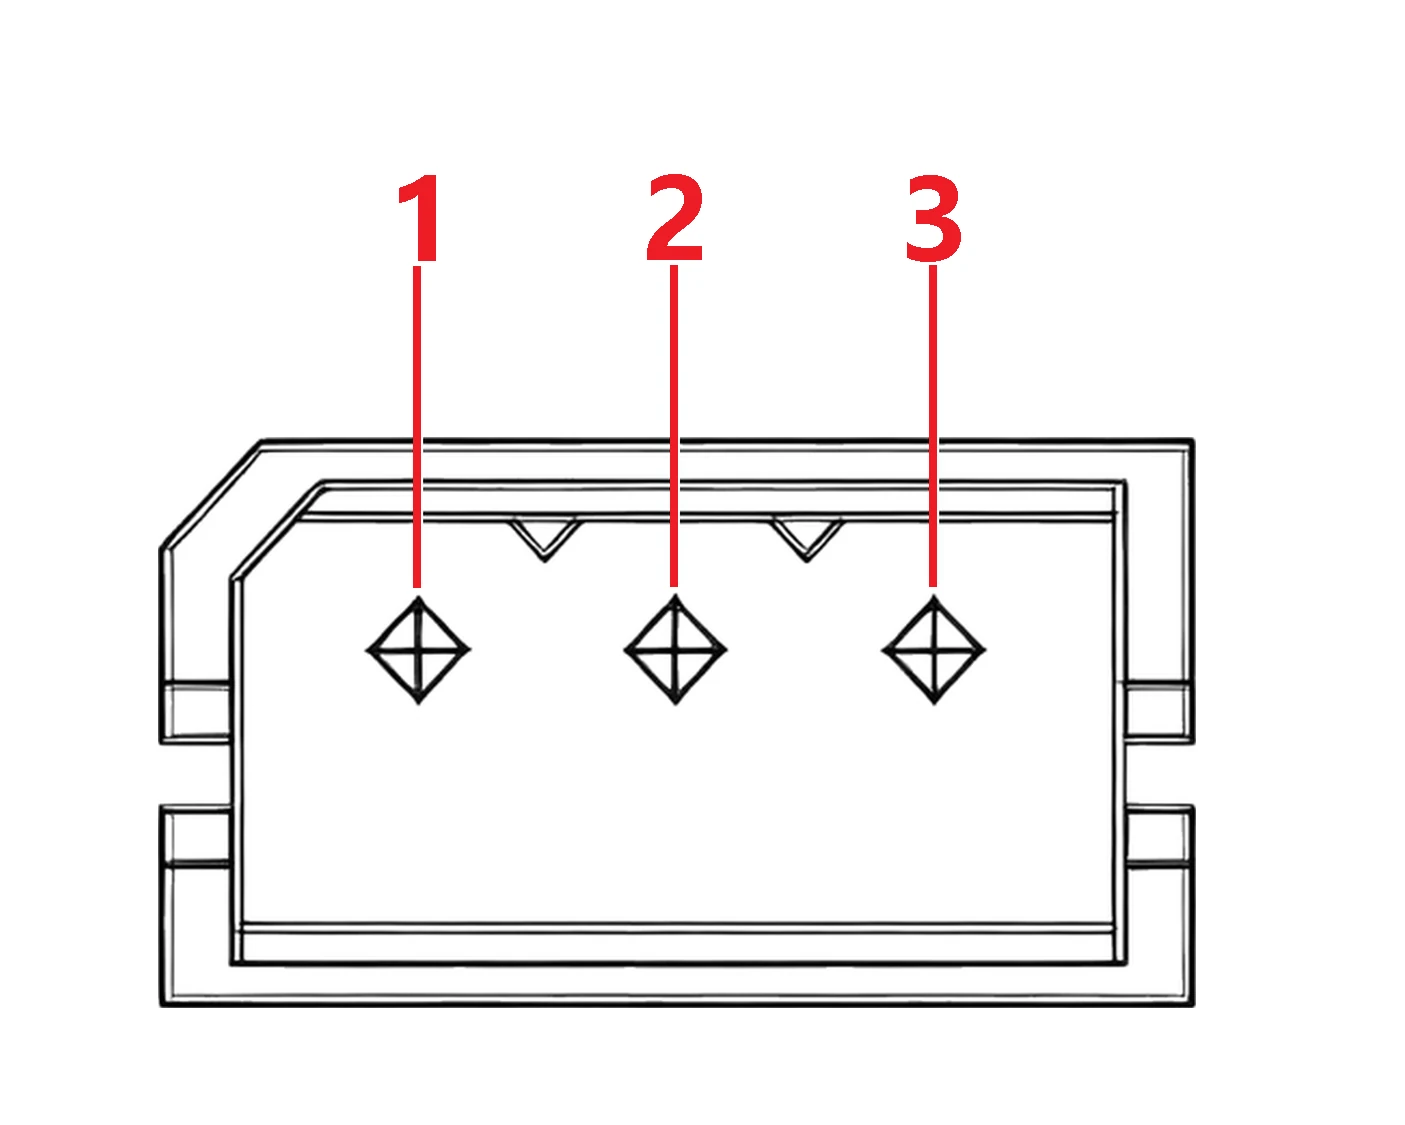
Pinout 4: 5264-3P terminal
 |
|
A black 3-pin connector (5264-3P, 2.5 mm pitch family). Wire colours and applicable models follow the physical unit and the supplied drawings.
All four pinouts share the same electrical and bus characteristics, summarised below:
| Item | Notes |
|---|---|
| Wires | 3: Signal (serial signal), Vcc (supply positive), GND (supply negative, signal ground) |
| Pinout | Identical across the four: 1 = Signal (TTL serial signal) · 2 = Vcc (supply positive) · 3 = GND (supply negative, signal ground) |
| How the signal travels | Single-ended half duplex, one data wire shared by transmit and receive (how the UART side becomes one Signal wire is shown in Figure 1); avoid star branches |
| Addressing | By ID; several servos are daisy-chained on one bus |
| Read-back | Yes — position, speed, voltage, temperature and more (see the memory table) |
| Matching debug board | FE-URT2-C001 (see Debug Boards and Adapters) |
| Models on this site | SCS (SC- 18 models), STS (ST- 20 models), HLS (HL- 17 models), HD (HD- 1 model), 56 TTL models in total |
| Read more | Bus servo setup · Protocol and parameters |
RS-485 bus
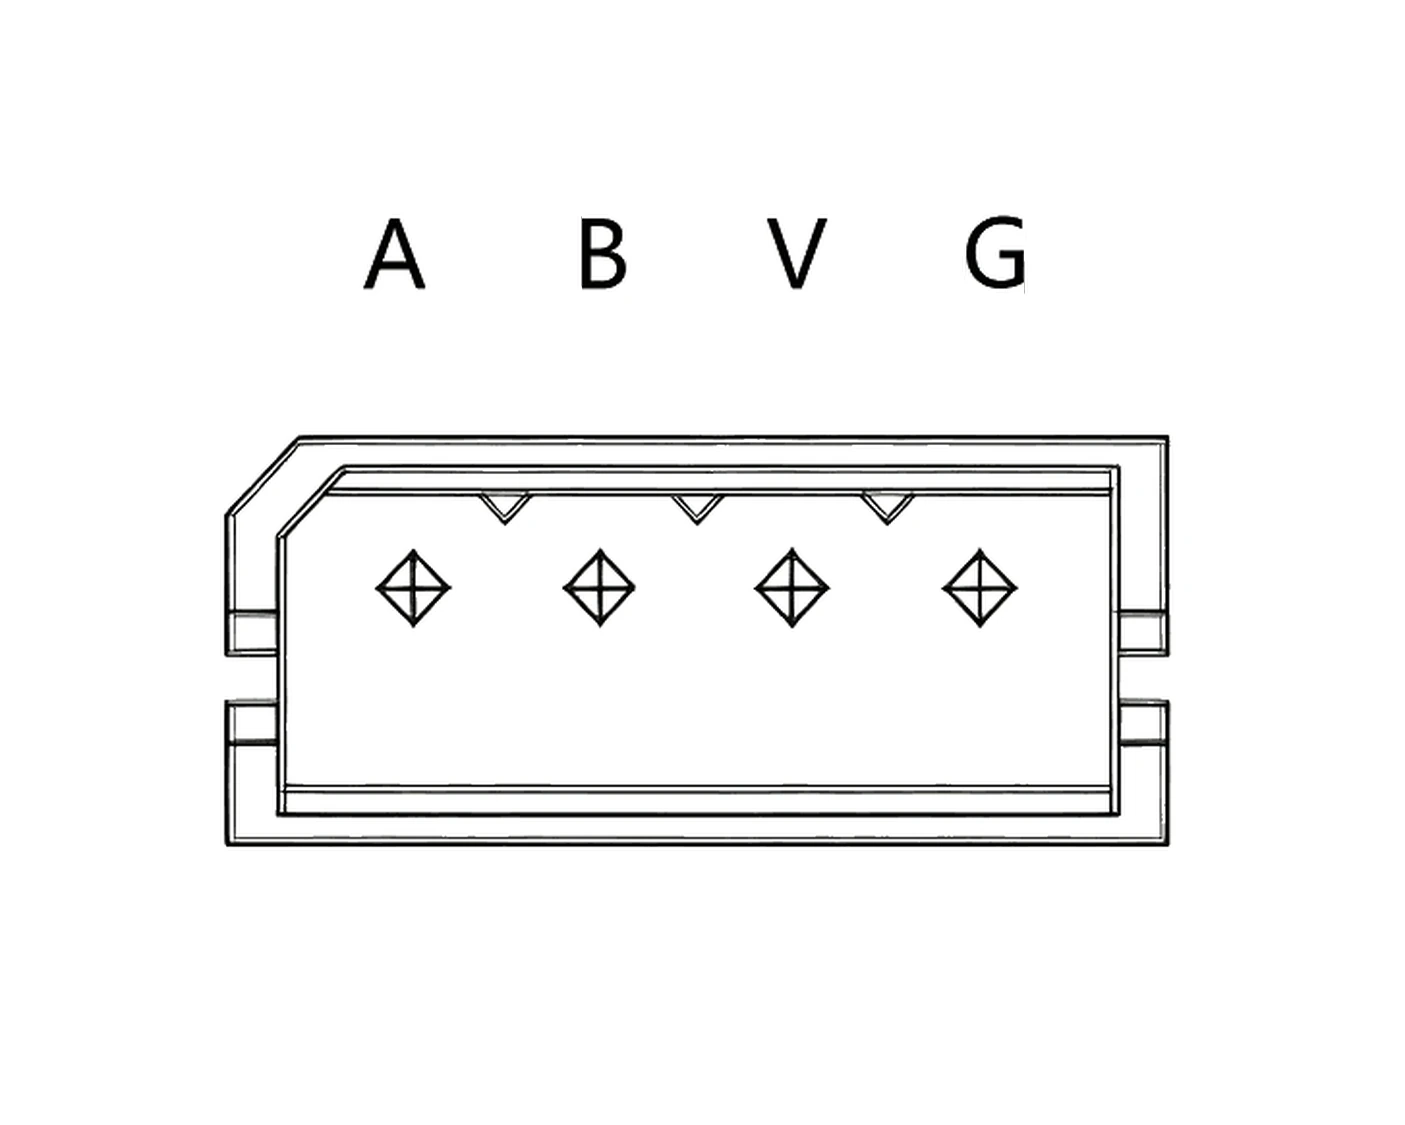
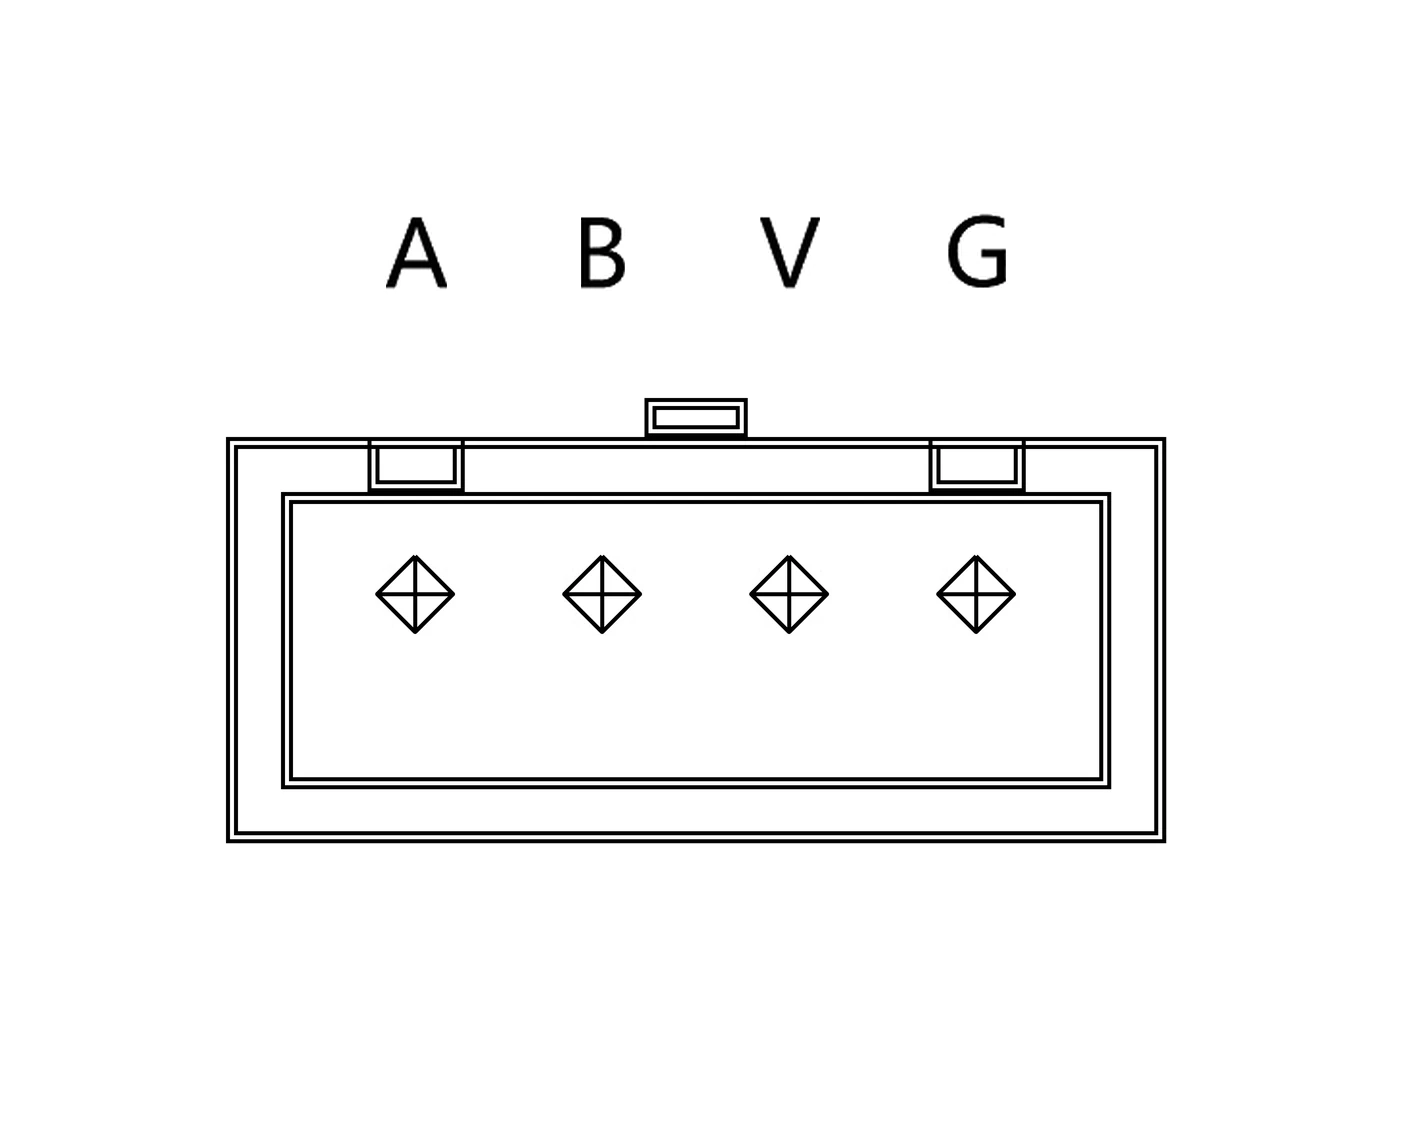
RS-485 bus servos have two common pinouts with an identical harness: 4 wires, pinout 1 = A · 2 = B · 3 = V · 4 = G.
Pinout 1: 5264-4P terminal
 |
|
A 4-pin connector (5264-4P, 2.5 mm pitch family).
Pinout 2: TJC25020-4P terminal
 |
|
A 4-pin connector (TJC25020-4P, 2.5 mm pitch family). It belongs to a different terminal family from pinout 1, so the two must not be interchanged.
The two pinouts have exactly the same pin order and harness; if an individual model differs, follow the physical unit and the supplied drawings.
| Item | Notes |
|---|---|
| Wires | 4: A, B (differential pair), supply positive (V), ground (G) |
| Connector | 5264-4P or TJC25020-4P (both 2.5 mm) — same pin order, different terminal families, must not be interchanged |
| Pinout | 1 = A · 2 = B · 3 = V · 4 = G; A/B must not be swapped; if an individual model differs, follow the physical unit and the supplied drawings |
| How the signal travels | Differential half duplex — logic read from the voltage difference between A and B; strong common-mode immunity, works over long runs |
| Addressing | By address (station number). The SMS protocol uses the same frame format as TTL and differs only in the physical layer, but SM- also contains MODBUS-RTU models with a different frame format, so the model page's marking decides (protocol details in Protocol and parameters) |
| Read-back | Yes, with the same capabilities as TTL |
| Matching debug board | FE-URT2-C001 (the same board carries an RS-485 port; see Debug Boards and Adapters) |
| Models on this site | SM- family, 27 models in total (mostly SMS protocol, plus MODBUS-RTU models) |
| Read more | Bus servo setup · SMS memory table · MODBUS-RTU Protocol |
The V and G in the table above mean the same as Vcc and GND on the TTL side; the wording simply follows the model documents.
PWM (pulse-width modulation)
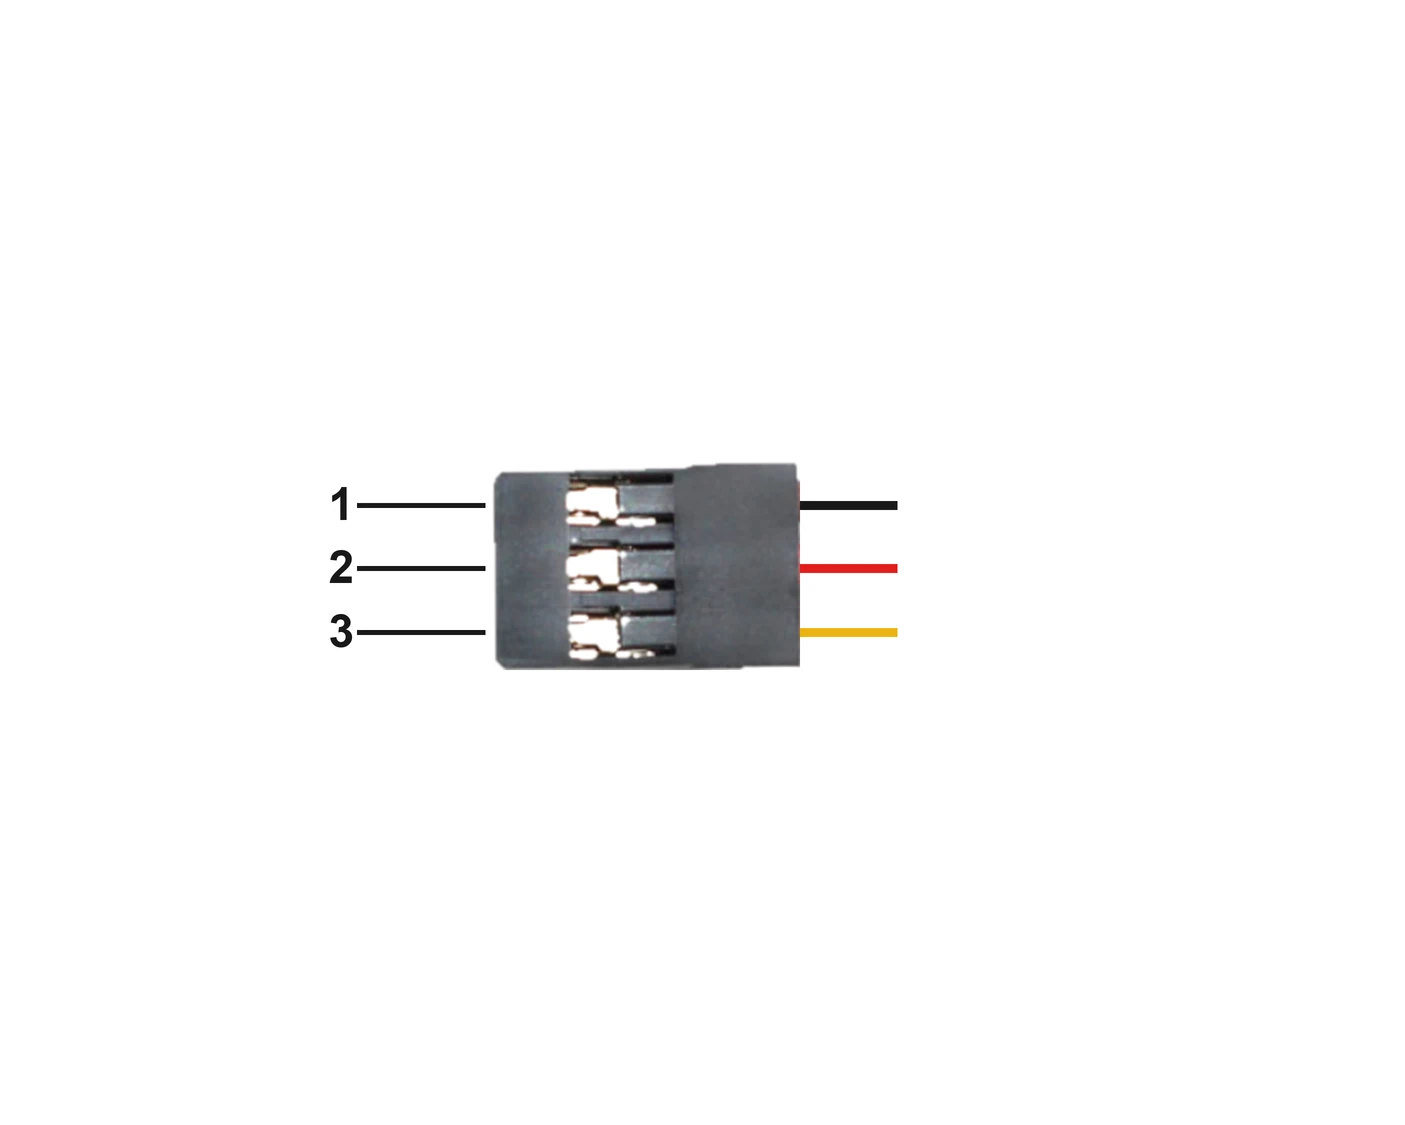
The PWM interface is shown here as the common 3-pin connector:
 |
|
The PWM harness and pinout vary by model, with no common standard; follow your model's documents and the controller it is paired with.
| Item | Notes |
|---|---|
| Wires | Commonly 3: supply positive (V+), ground (GND), signal; the actual set follows your model's documents |
| Pinout | Decided by the specific model and controller documents; do not apply another model's |
| How the signal travels | A pulse with a period of about 20 ms, where pulse width sets the position (commonly 0.5–2.5 ms; see your model) |
| Addressing | No ID — one signal wire controls one servo, so several servos mean several wires |
| Read-back | No (some models can read back one-way on the signal wire; follow the documents) |
| Matching debug board | Programmable models can take parameters (travel limits and so on) from FE-FRS1-C001 / FE-SCPC-C003; the procedure and tools are in PWM servo setup; the signal comes from an MCU PWM output or an RC receiver |
| Models on this site | PWM family (FT / FB / FS / FR / FI prefixes), 86 models in total |
| Read more | PWM servo setup · PWM series specifications |
CAN bus (UAVCAN)
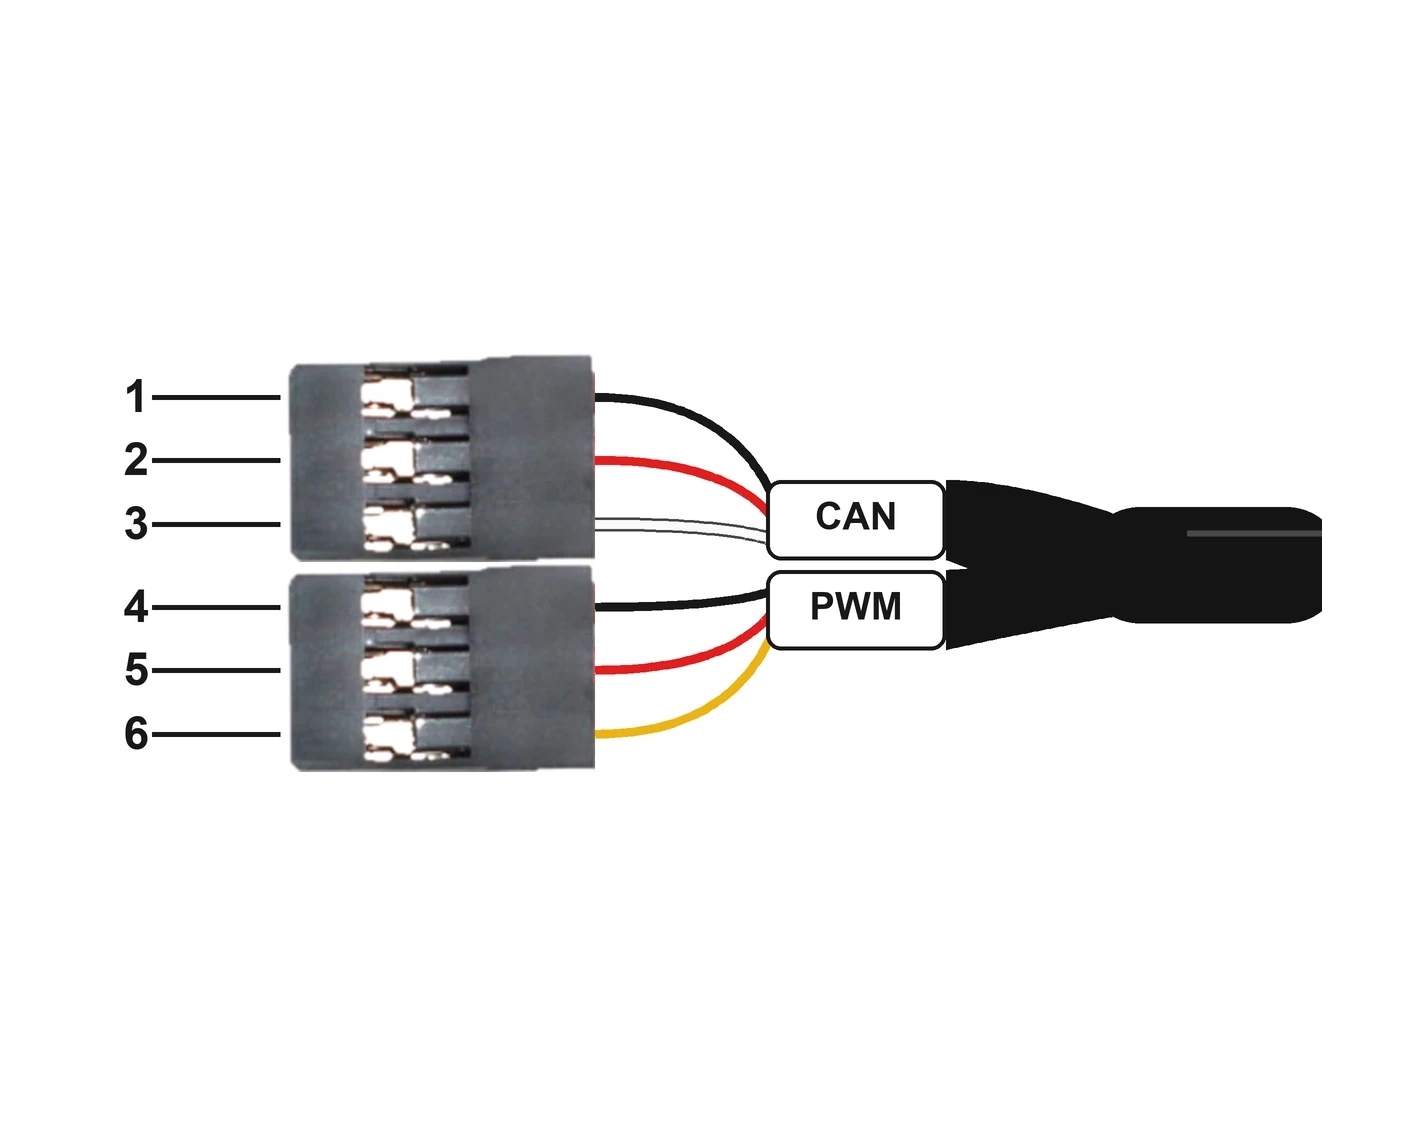
The CAN interface is shown here with FU-8830: the harness has 6 pins in two groups — CAN group (pins 1–3) and PWM group (pins 4–6).
 |
|
CAN communication uses the CAN group (the CAN-H / CAN-L pair and ground); power comes from Vcc and GND.
The CAN harness and pinout vary by model; follow the specific model's documents.
| Item | Notes |
|---|---|
| Wires | FU-8830 as an example: 6 pins in two groups of 3 — CAN group (GND, CAN-L, CAN-H) and PWM group (GND, Vcc, Signal); other models follow their documents |
| Pinout | 1 GND · 2 CAN-L · 3 CAN-H · 4 GND · 5 Vcc · 6 Signal (FU-8830, matching the image above) |
| How the signal travels | Differential bus with multi-master arbitration; the controller side needs a transceiver, and each end of the bus needs a 120 Ω termination resistor |
| Addressing | Every node has a unique NODE_ID |
| Baud rate | 1M from the factory, configurable 20K–1M (follow your model's documents) |
| Read-back | Yes, through UAVCAN paged registers; not compatible with SCS/STS/HLS memory tables |
| Matching debug board | FE-SCPC-C003 (USB to CAN; see Debug Boards and Adapters) |
| Models on this site | FU family (FU-), 1 model in total |
| Read more | Bus servo setup · UAVCAN Protocol |
Pinout and harness follow the physical unit and the supplied drawings
Interface identification and wiring details are in Power and Wiring; the pinout, wire colours and harness composition follow the physical unit and the supplied drawings, and you photograph the actual wiring as your record. The document status of a model and the entry point for requesting missing items are in Product Selection.
Keep a result at each stage
| Stage | What this step needs | Record on completion | Main landing page | If it fails |
|---|---|---|---|---|
| Model identification | Label, suffix and document revision | How the hardware maps to the documents | Series and Interfaces | Request the missing documents from the model page |
| Wiring preparation | Supply, pinout, adapter/controller, common ground | Wiring photos and the actual configuration | Power and Wiring | Go through the pre-power checks item by item |
| Establishing communication | A matching debug board and interface, this model's factory baud rate | Identity response, raw ID and baud rate | Bus servo setup | Troubleshooting |
| First-motion validation | No load, servo travel space cleared, accurate control parameters | Motion response, faults and the stop method | First Motion · PWM servo setup | Troubleshooting |
| Software integration | A validated configuration and a matching example | Platform, code revision and a reproducible record | SDK Overview · PWM servo setup | Go back to the validated example and compare item by item |
| Mechanical integration | Drawings, model, zero position and permitted travel | Assembly and interference validation record | Mechanics and assembly | Re-check the zero position and software limits |
Figure 2 (Getting-started path · Stage order): the order of stages 1 to 6; the dashed line is the PWM route, which skips establishing communication; the stage names are in the table above.
"Establishing communication" applies to the bus routes only; the PWM route has no communication to establish, and both its signal confirmation and its first motion happen on the PWM servo setup page.
Some models currently have only a specification summary; dedicated pinouts, CAD or examples are not supplied. Check the model's document status rather than substituting generic parameters for missing information.