Bus servo setup
Back to the getting-started path
This flow is for anyone using a FEETECH bus servo for the first time, and covers the TTL and RS-485 serial buses plus the CAN bus (FU series). For an ordinary PWM servo, see PWM servo setup and use a PWM controller and pulse range that match the model.
This page only covers powering up and establishing communication; wiring and power supply are in Power and Wiring, and the first motion once communication is stable is in First Motion.
Gather parts
The power supply, harnesses and terminal cables are shared between the (bus / PWM) routes; the host software and serial driver are specific to the bus route. See the checklist in Power and Wiring — this page only adds the bus-specific items on top of it.
Required
- One FEETECH bus servo with a confirmed model (if the model is unclear, start from Series and Interfaces)
- A USB debug board matching the interface:
FE-URT2-C001for TTL and RS-485,FE-SCPC-C003for CAN (see Debug Boards and Adapters) - A data-capable USB cable and bus connection cables
- A Windows PC with the serial debug tool UartAssist, used on this page to send hexadecimal command frames and do read-only checks — on the download page click "Download" to get the zip; it runs directly after extraction, no installation needed
- The CAN route additionally needs the UAVCAN debug tool FUServo_Debuger (on the download page click "Download" to get the 7z archive; it runs directly after extraction; screenshots use version V1.4)
Optional
- A development device for Python / Arduino / STM32 — leave it to the SDK Overview stage
Figure 1 (This page's flow · Task chain): this page is one task chain executed in order, with the numbering continuing in the next two sections — everything is read-only (no parameters are written); the last box, verify identity (model, ID, baud rate), confirms that reads are stable.
Power-up order
- Run with no load (remove the load) and connect only one servo.
- With power off, check the power polarity, the signal wire and the ground wire (see the pre-power checklist in Power and Wiring).
- Connect the debug board to the computer first, then switch on the servo side's external power.
Stalls and reversed polarity can damage equipment
The USB port must not power the servo's motor. Reversed polarity, overvoltage, a prolonged stall, a collision of the mechanism, or several servos with duplicate IDs moving at once into their end stops can damage the servo, the debug board or the computer.
Establish communication
After step 3 of the power-up order, the following 3 steps continue the numbering (6 steps in total on this page). These 3 steps are all read-only: they only query status and write no parameters, and no motion command is sent before communication is confirmed.
Before step 4, make sure the computer has recognized the debug board's COM port: open the Device Manager → "Ports (COM & LPT)" and note the port, then open UartAssist directly; if it is not recognized, install the debug board's driver first (see Debug Boards and Adapters) and continue from step 4 once the COM port appears.
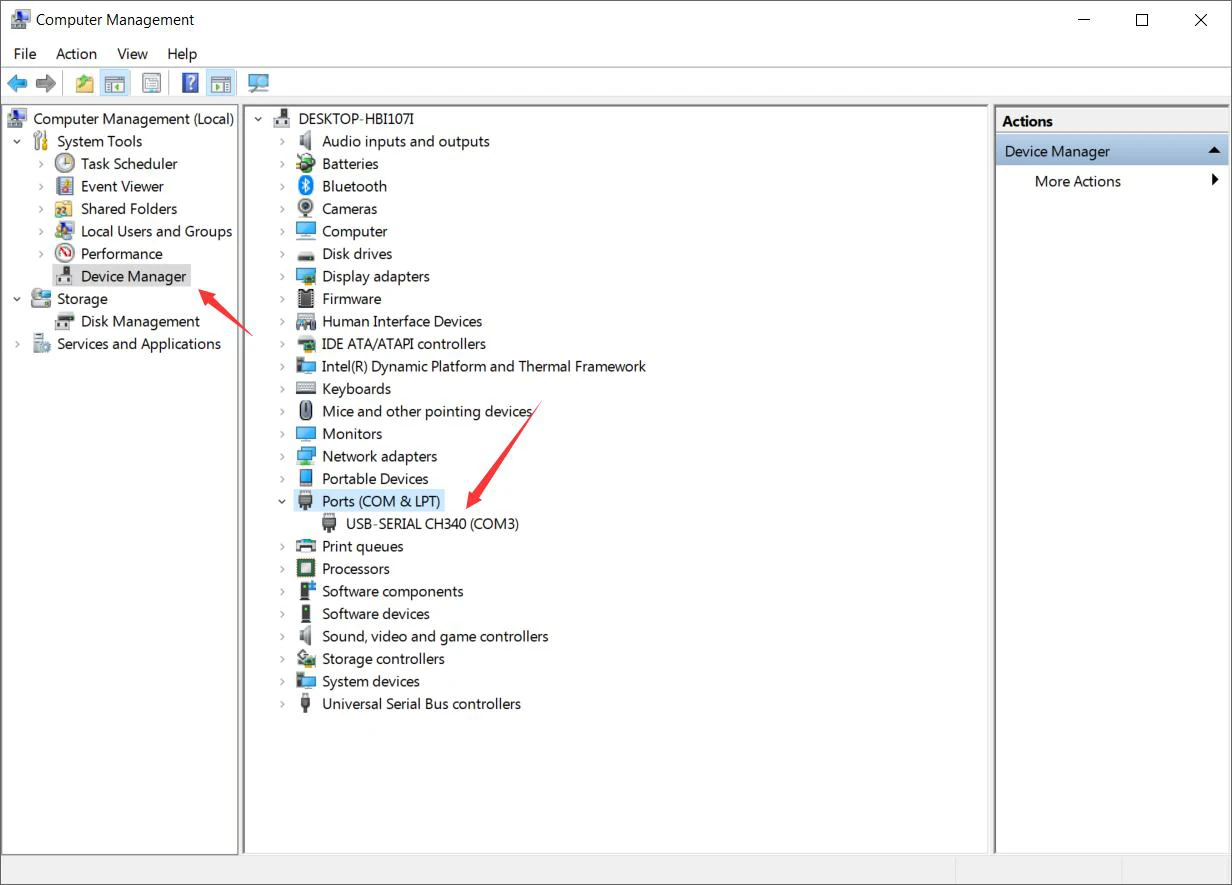
Figure 2 (Establish communication · Confirm the COM port): once the debug board's driver is installed, confirm the port number in the Device Manager under "Ports (COM & LPT)" (COM3 in the figure; the number on your computer may differ).
- Confirm the model's application layer (the protocol used by the series, as marked on the model page) and follow the matching branch:
- FT-SCS protocol models (the SCS / STS / HLS and SMS-protocol series) send a PING command frame with UartAssist (PING, also called the "query status" command, only reads the working status and does not change the servo), with the model's factory baud rate (common factory values in the note below); the steps are in Figure 3 to Figure 5 below
- Modbus-RTU models do not respond to PING frames — go to "How Modbus-RTU models differ" below
- CAN (FU series) uses the UAVCAN debug tool — see "How CAN bus (FU series) differs" below
- Record these two values: the ID and the baud rate — the ID comes from the ID field of the FT-SCS PING reply frame, the slave address of the Modbus-RTU reply frame, or the NODE field for CAN; the baud rate is the value that actually connected in step 4.
- If replies arrive stably on repeated sends (for CAN, the target node keeps reporting feedback), the connection is good; after confirming the control mode, units and allowed range (see Protocol and parameters), this page ends — the first motion is in First Motion.
Common factory baud rates
The official starter-tutorial rule — with a wrong baud rate or no power to the servo, a PING gets no reply. Factory values by series:
- SCS/STS series: factory 1000000
- SMS-protocol series: factory 115200
- CAN (FU series): factory 1M — see "How CAN bus (FU series) differs" below
Factory baud rates are listed in the parameter tables on the model pages and in the datasheets; for other series and for devices with changed parameters, the model's own documentation is authoritative. If there is still no reply at the model's factory value, check power supply and wiring first, then try the other candidate values of the same series one by one (for devices whose baud rate was changed or is uncertain).
For FT-SCS protocol models, step 4 breaks into three sub-steps (software version V5.0.1; the UI may differ by version):
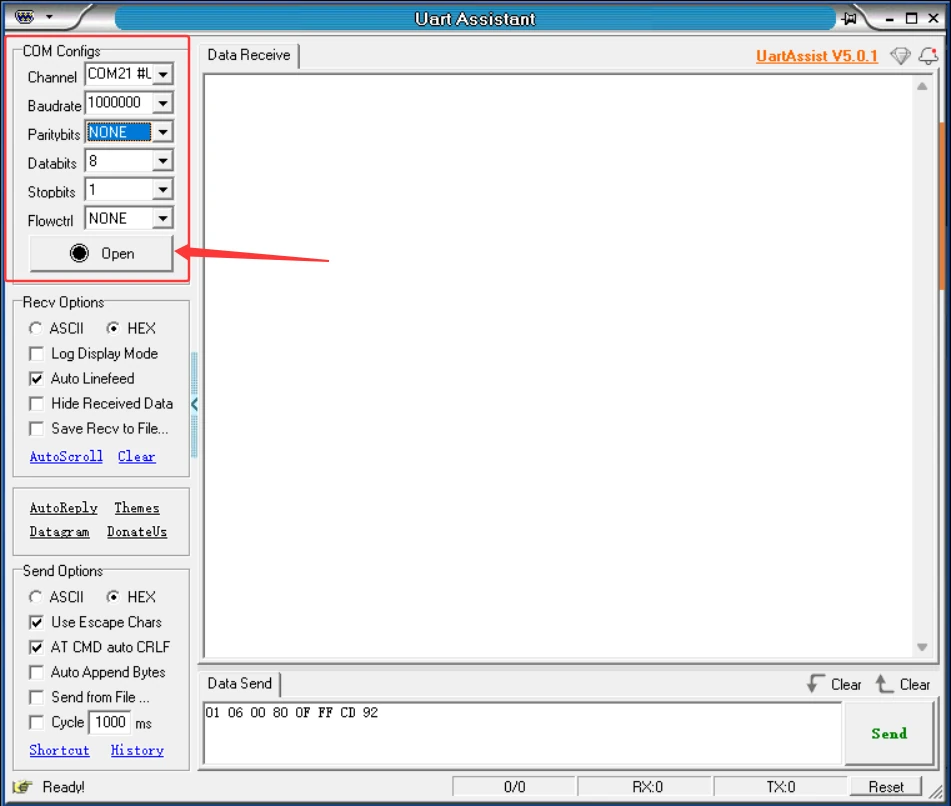
Figure 3 (TTL / RS-485 bus · Serial settings): double-click to open UartAssist and set, in the "COM Configs" area, in order:
- Channel: select the debug board's COM port (COM21 in the figure; use your own port).
- Baudrate: select the servo's factory value (1000000 in the figure is the SCS/STS factory value; the SMS-protocol series uses 115200).
- Paritybits NONE, Databits 8, Stopbits 1, Flowctrl NONE.
- Select HEX in both "Recv Options" and "Send Options".
- Click "Open".
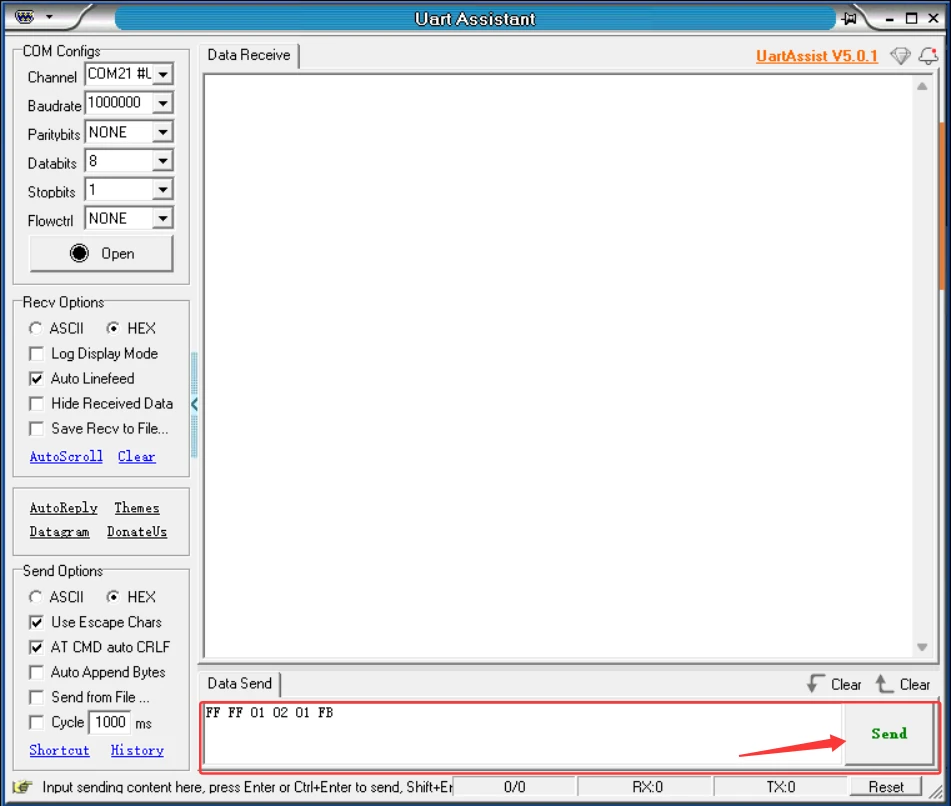
Figure 4 (TTL / RS-485 bus · Send the PING frame):
- In the "Data Send" area at the bottom, enter the PING frame
FF FF 01 02 01 FB— the frame for factory default ID 1; for a different ID, replace the third byte with the actual ID and recompute the checksum; if you do not know the ID, send the broadcast PINGFF FF FE 02 01 FEinstead — the third byte of the reply frame is this servo's ID (the broadcast PING only works when, as on this page, the bus has a single servo). The full frame structure and checksum algorithm are in the FT-SCS Protocol. - Click "Send".
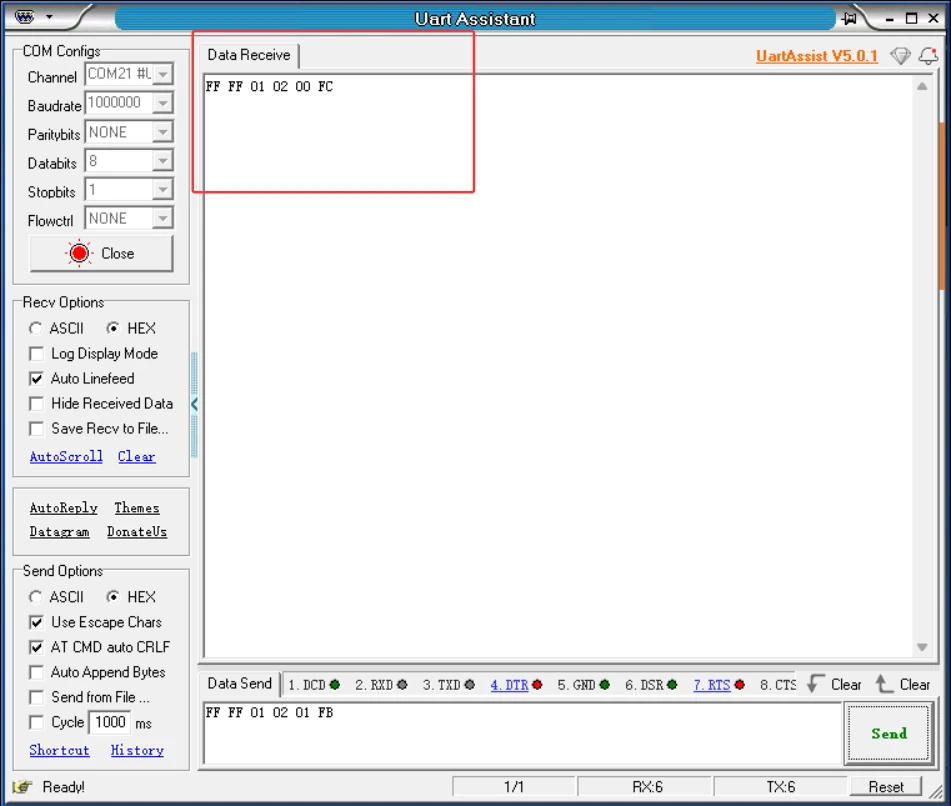
Figure 5 (TTL / RS-485 bus · Reply received):
- The "Data Receive" area shows the reply frame
FF FF 01 02 00 FC— the connection is good; the fifth byte of the reply frame (the status code)00means the servo is in a normal state with no errors. - Clicking "Send" repeatedly keeps returning stable replies.
- When finished, click "Close" to release the serial port.
Once these steps pass (stable PING replies), communication is confirmed — continue to First Motion.
How Modbus-RTU models differ
For Modbus-RTU models the model page is authoritative: a model belongs here when its parameter table marks Modbus-RTU. It also uses the serial debug tool and its physical layer is the same as RS-485, but its command frames are Modbus-RTU format and it does not respond to the FT-SCS PING frame above.
Under the SM- prefix, the SMS protocol and Modbus-RTU coexist — the two are not the same thing:
- SMS is the in-house protocol — see the SMS memory table
- SMSMB is the Modbus-RTU memory table
The differences from the RS-485 route are in the table below:
| Aspect | Modbus-RTU models |
|---|---|
| Physical layer | Same as RS-485, using FE-URT2-C001 (wiring in Power and Wiring) |
| Application layer | MODBUS-RTU Protocol; does not respond to the FT-SCS PING frame |
| Register addresses | See the SMSMB memory table |
| Factory serial config | 115200, 8 data bits, no parity, 1 stop bit, default station number (servo ID) 1; the model's documentation is authoritative |
Workflow (software version V5.0.1; the UI may differ by version):
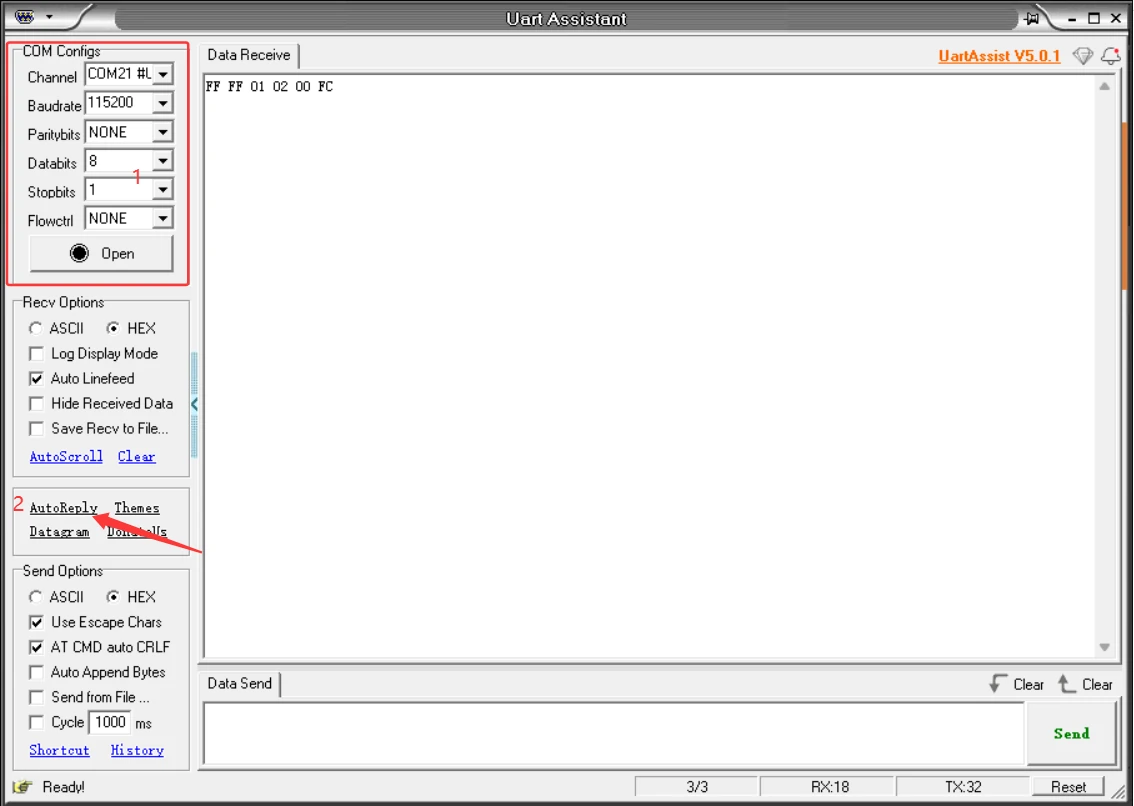
Figure 6 (Modbus-RTU · Serial settings and entry): double-click to open UartAssist, then:
- In "COM Configs", select the correct port number (COM21 in the figure; use your own computer's port).
- Baudrate 115200 (the Modbus models' factory value), Paritybits NONE, Databits 8, Stopbits 1, Flowctrl NONE.
- Click "Open".
- Click "AutoReply" at the lower left — this button opens the Modbus debug entry.
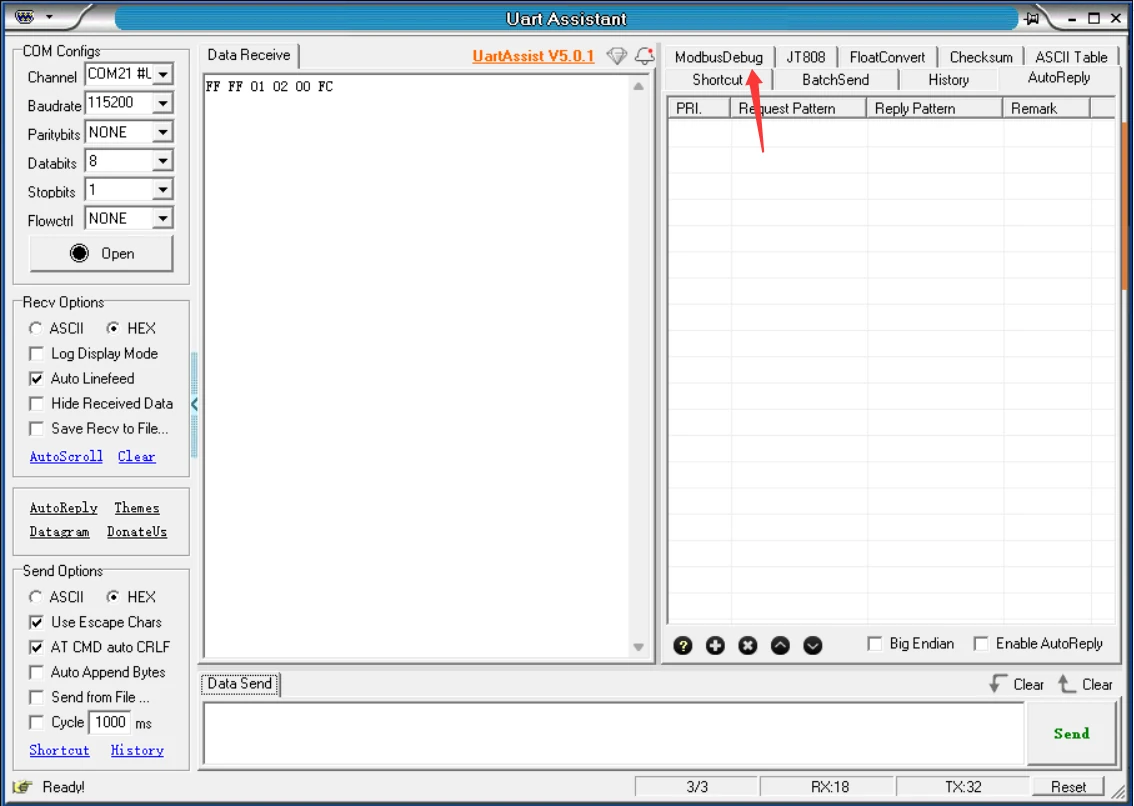
Figure 7 (Modbus-RTU · Open the Modbus debug panel):
- Click "AutoReply" — the instruction reply template area appears at the top right.
- Click the "ModbusDebug" button in it to open the Modbus debug panel.
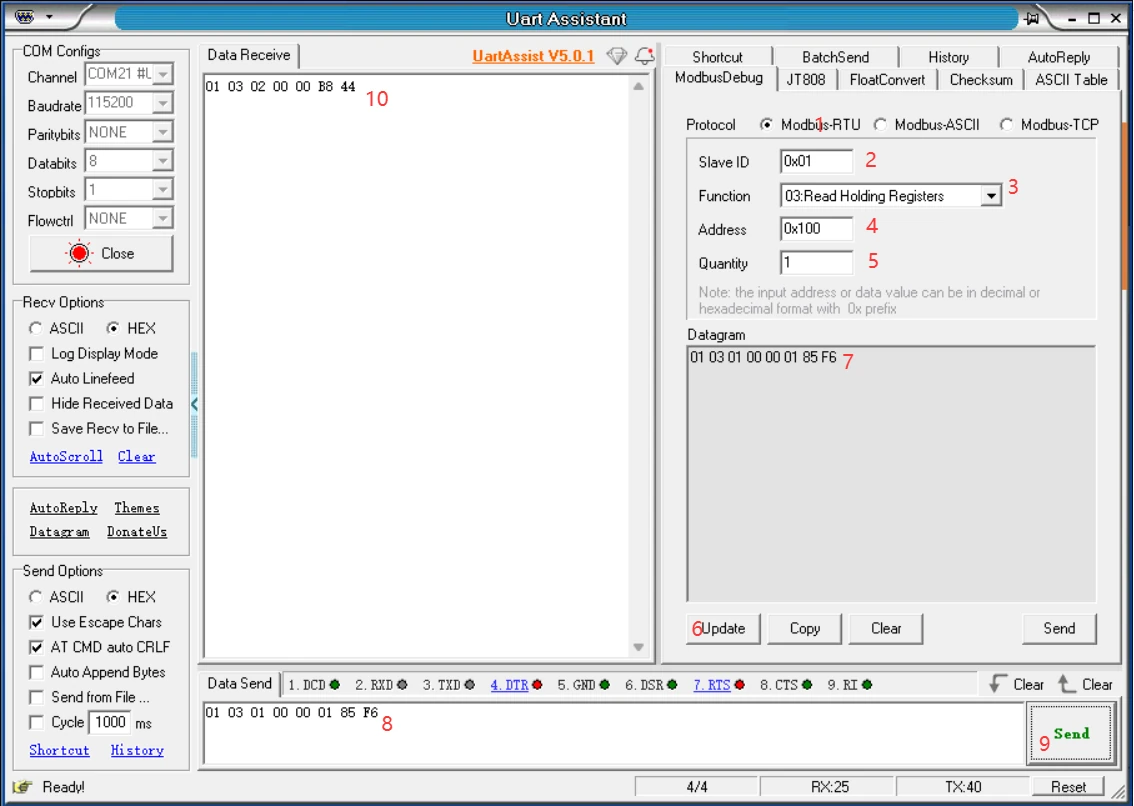
Figure 8 (Modbus-RTU · Fill parameters, send and receive the reply): the red numbers 1 to 10 in the figure mark the full order from filling in the parameters to receiving the reply:
- Protocol: select Modbus-RTU (number 1).
- Slave ID = the servo ID (0x01 in the figure, the default station number, number 2).
- Function = the Modbus function code (03:Read Holding Registers in the figure, number 3).
- Address: fill it in per the SMSMB memory table (0x100 in the figure is the address of "servo status", number 4).
- Quantity is the number of registers to read (1 in the figure; one register = 1 Word = 16 bit, which corresponds to 2 data bytes in the reply, number 5).
- When done, click "Update" (number 6) — the "Datagram" area generates the hexadecimal frame (
01 03 01 00 00 01 85 F6in the figure, number 7). - Copy the frame to the "Data Send" area at the bottom (number 8) and click "Send" (number 9).
- The "Data Receive" area shows the servo's reply frame (
01 03 02 00 00 B8 44in the figure, number 10) — the connection is good.
Once this flow passes (stable reply frames), communication is confirmed the same way — continue to First Motion.
How CAN bus (FU series) differs
CAN bus servos follow the same "single servo, no load, communication before motion" rule; the differences are in the physical interface and the application layer:
| Aspect | CAN (FU series) |
|---|---|
| Physical layer | Uses the USB-to-CAN debug board FE-SCPC-C003; CAN needs a transceiver and termination resistors and cannot be connected to a TTL or RS-485 port |
| Application layer | UAVCAN Protocol; does not use the registers and memory tables of SCS/STS/HLS |
| Parameter addresses | Paged registers (page × 64 + index), see the UAVCAN memory table |
| Factory baud rate | Factory default 1M (configurable 20K–1M), changeable with the host software; the model's documentation is authoritative |
| Node address | Every node's NODE_ID must be unique; read the node status and feedback first and confirm communication is stable before sending position commands |
CAN sends no protocol frames
In step 4, FT-SCS and Modbus-RTU both use the serial debug tool (UartAssist), while CAN (FU series) does not use UartAssist — use the UAVCAN debug tool instead (where to get it: "Gather parts" above). Set the communication settings and open the port as in the figure below, then click Start; if the target node's feedback keeps updating, communication with this CAN servo is good (the NODE on the left is set correctly and the servo is online).
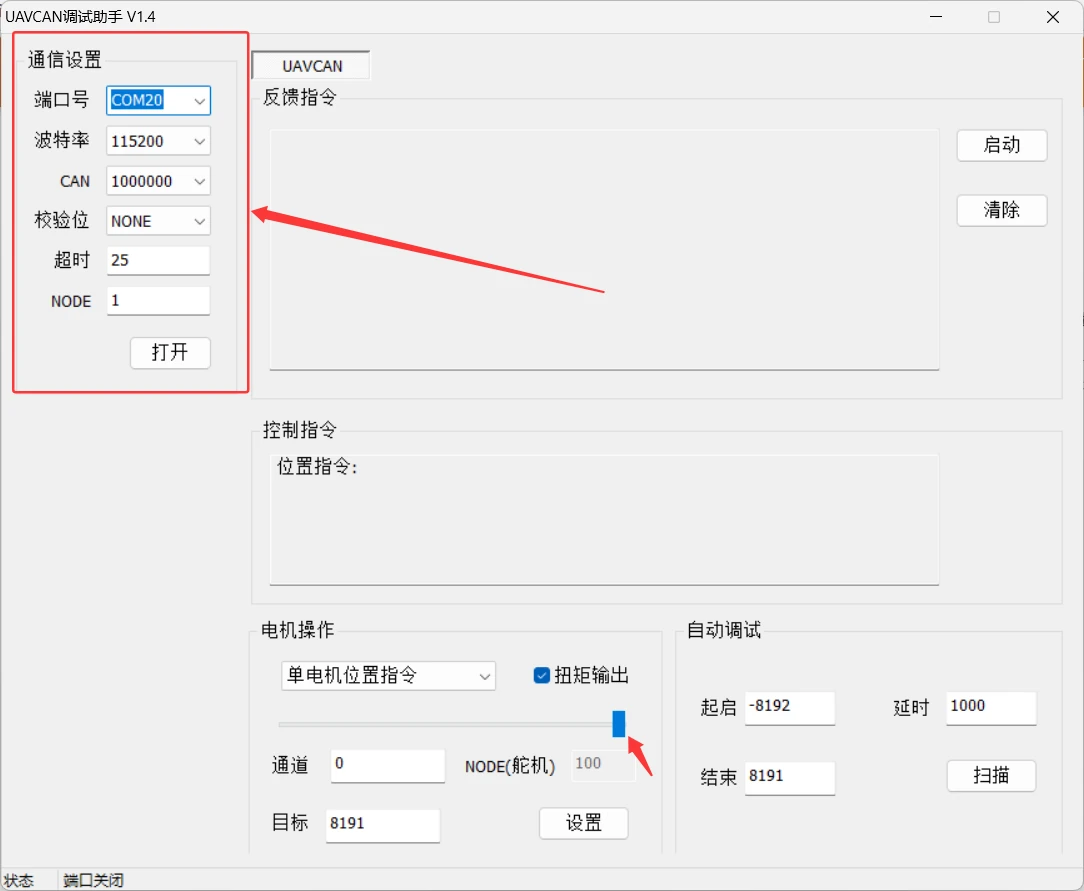
Figure 9 (CAN bus · Communication settings): the CAN communication settings are all in the left area; after setting them, click Open (UAVCAN debug tool, screenshot version V1.4; the screenshots keep the tool's original Chinese UI, and each Chinese label below is followed by its meaning):
- From top to bottom, the left side holds the port number (端口号), the host baud rate (波特率), the CAN rate (CAN), the parity (校验位), the timeout (超时) and NODE.
- The two rates are not the same thing: 波特率 (Baudrate) is the communication rate between the host software and the USB-CAN debug board (
FE-SCPC-C003, i.e. SCPC-3) (115200 in the figure, unrelated to the servo itself); CAN is the servo's baud rate on the bus, the rate the board uses to talk to the servo — 1000000, i.e. 1M, in the figure, matching the common factory baud rates above. - If this model's factory value differs, change the CAN field accordingly; every field's value follows the model's documentation.
- Click 打开 (Open) — the status bar at the bottom changes from 端口关闭 (port closed) to 端口打开 (port open), and the button becomes 关闭 (Close).
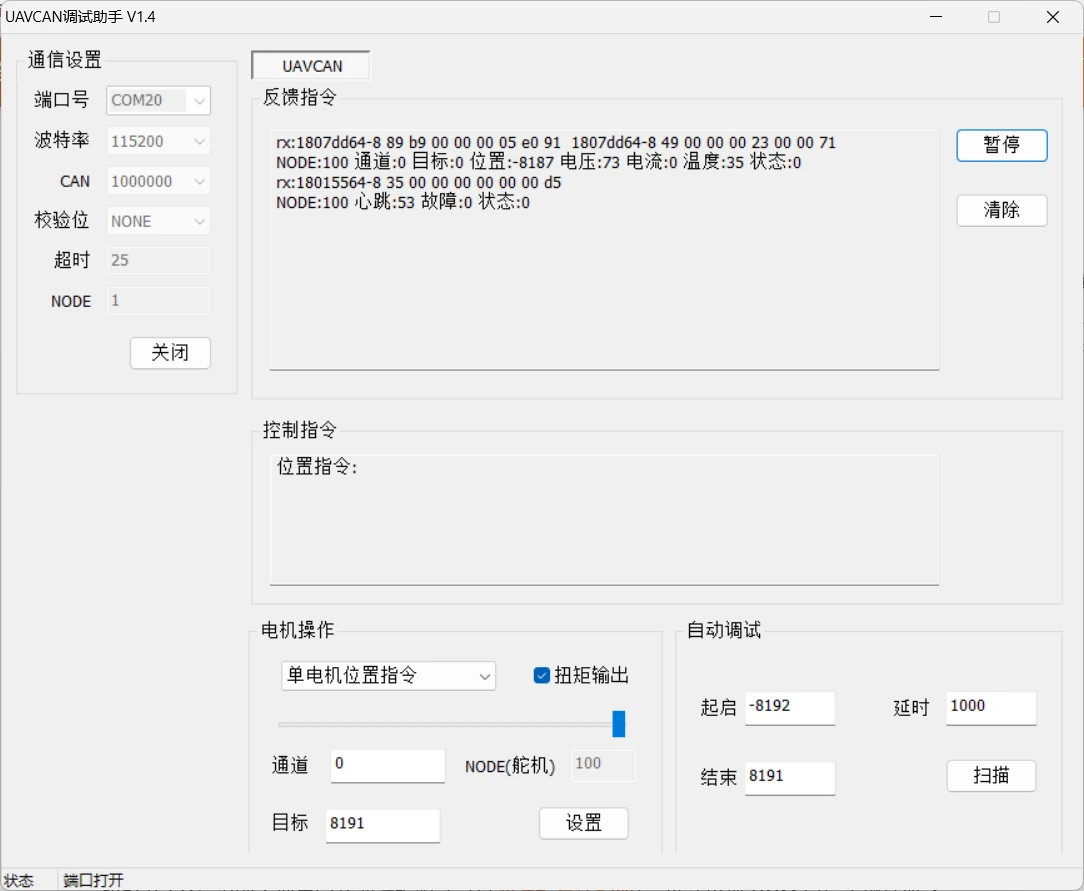
Figure 10 (CAN bus · Feedback check): after clicking 启动 (Start), the feedback area keeps updating:
- In the feedback area (反馈指令), each raw frame (e.g.
rx:…) is followed by decoded fields (NODE, channel, target, position, voltage, current, temperature, status) plus heartbeat and fault lines. - If the target node's feedback keeps updating, communication with this CAN servo is good (the NODE on the left matches the servo and the servo is online) — the check required by step 4.
- 暂停 (Pause) stops the refresh, 清除 (Clear) empties the log.
- The position, voltage and temperature values in the figure are examples; the model's documentation is authoritative.
Once this is stable, communication is confirmed the same way — continue to First Motion.
Expanding to several servos
Only expand the bus after the single-servo check passes, one servo at a time: connect one, confirm communication, then the next. Re-verify identity after every addition:
- FT-SCS: send PING
- Modbus: read a register
- CAN: watch the node feedback
On the same bus, IDs must be unique and the baud rate must match; cabling and grouped power supply, CAN termination resistors and other rules are in Power and Wiring.
How to change the ID / station number:
- FT-SCS models: write to the memory table's "ID" address (5) with the broadcast ID
0xFE, turning off the EEPROM protection lock first (see the FT-SCS Protocol, example 3) - Modbus-RTU models: change the "ID" register (address 0x0A) in the SMSMB memory table
- CAN models: set NODE_ID with the host software (see the UAVCAN memory table)
Synchronized writes, multi-servo control, exception timeouts and mechanical end stops in code are covered in the SDK Overview.
Records to keep afterwards
Keep a record of the model and application layer, the debug board model, the power supply method, the original ID (NODE_ID for CAN), the baud rate, the control mode, and one stable reply (a PING reply for FT-SCS, a read reply for Modbus-RTU, node feedback for CAN); when the ID or baud rate changes at the multi-servo stage, record the old and new values together. Re-confirm after changing wiring, the debug board or firmware; do not carry over this record.
Next steps
- First Motion: one controlled motion once communication is stable, and how to stop it
- Protocol and parameters: full details on control modes, units and register addresses
- FT-SCS Protocol: frame structure and checksum algorithm — the full source of this page's PING frames
- SDK Overview: move the verified configuration into code
- Troubleshooting: no reply, or the servo cannot be found after an ID / baud rate change