HL-2909-C001
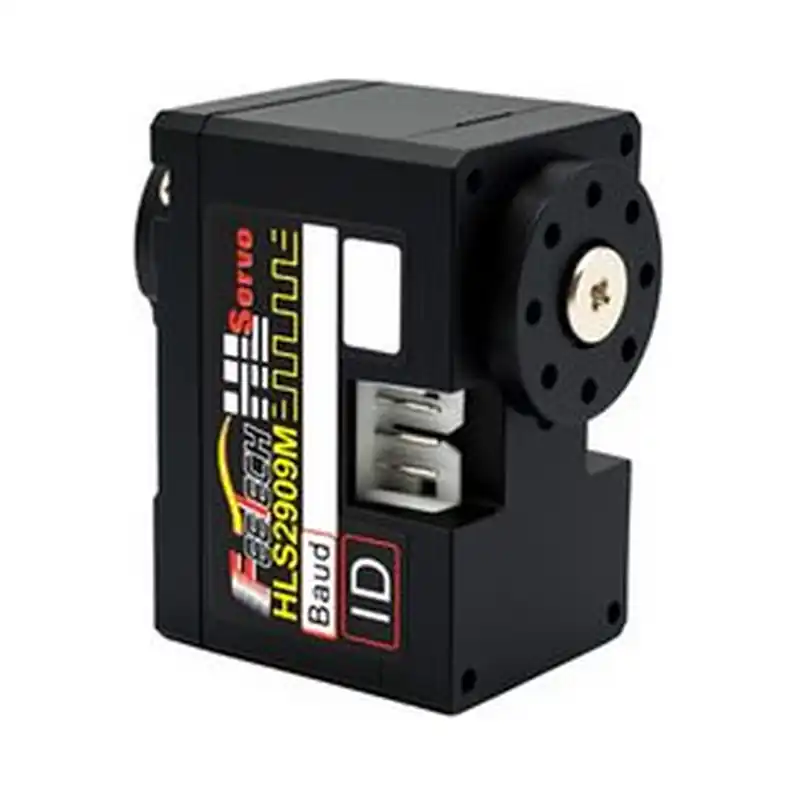
Specifications transcribed from the supplied documentation for this exact model and suffix.
Start your integration
| Your task | Start here | What to check |
|---|---|---|
| Write control software | Software integration | Interface, application layer, read-first bring-up and validation record |
| Design a bracket or joint | Mechanical integration | Drawings, CAD, datum, output shaft and cable clearance |
| Collect engineering files | Resources and status | Available files and outstanding information |
Key specifications
| Parameter | Specification |
|---|---|
| --- | --- |
| Input voltage | 9–14 V |
| Stall torque | 8.9 kg·cm@12V |
| No-load speed | 0.13 s/60°(77 RPM)@12V |
| Travel / rotation | 360°(0~4095,12-bitmagnetic encoder) |
| Control interface | TTL |
| Family | HLS |
| Dimensions | 34 × 20 × 23 mm |
| Weight | 22.5 ± 2 g |
| Gears | Metal gears(plastic case) |
| Motor | Iron-core motor |
| Communication | TTL half-duplex asynchronous serial,ID 0–253,38400bps ~ 1Mbps |
| Shaft structure | Dual-shaft output |
| Document revision | A/0(Official page captured 2026-10-02) |
Selection note
Stall torque is a short-duration limit, not continuous operating torque. Confirm power, shared ground, interface and mechanical clearance before enabling torque.
Official model specifications
FEETECH official product page · Checked 2026-10-02. The complete model on the page is HL-2909-C001.
| Parameter | Manufacturer specification |
|---|---|
| Model | HL-2909-C001 |
| Storage Temperature Range | -30℃~80℃ |
| Operating Temperature Range | -10℃~60℃ |
| Temperature Range | 25℃ ±5℃ |
| Humidity Range | 65%±10% |
| Size | A: 34mm B: 20mm C: 23mm |
| Weight | 22.5±2g |
| Gear type | Metal Gear |
| Limit angle | No limit |
| Bearing | 滚珠轴承 Ball bearings |
| Horn gear spline | 25T/OD4.95mm |
| Gear Ratio | 1/320 |
| Back Lash | ≦1° |
| Case | PA+Fiber |
| Connector wire | 15CM/20CM |
| Motor | Core Motor |
| Rated Input Voltage | 9V-14V |
| No load speed | 0.13sec/60°(77RPM)@12V |
| Runnig current(at no load) | 140mA@12V |
| Peak stall torque | 8.9kg.cm@12V |
| Stall current | 0.6A@12V |
| Rated Load | 2.9kg. cm@12V |
| Rated current | 200mA@12V |
| KT | 14.83kg.cm/A |
| Operating Modes | 模式0:角度伺服模式 (默认此模式,0-360度[敏感词]位置可控) Mode 0: Angle servo mode (default mode, absolute position controllable from 0-360 degrees) |
| Multi-Loop Mode | [敏感词]精度下可以正负7圈[敏感词]位置控制,但掉电圈数不保存(扩大分辨率,圈数可翻倍) control of positive and negative 7 turns at the highest accuracy, but the umber of power failure turns is not saved (the resolution can be expanded, and the number of turns can be doubled) |
| Constant force output | 设定输出扭矩值,舵机可保持该扭矩(44号地址输入相对应的目标扭矩值,舵机可保持该扭矩) Set the output torque value, the servo can maintain this torque (input the target torque value corresponding to address 44, the servo can maintain this torque) |
| Command signal | Digital Packet |
| Protocol Type | Half Duplex Asynchronous Serial Communication |
| ID | 0-253 |
| Communication Speed | 38400bps ~ 1 Mbps |
| Control Algorithm | PID |
| Neutral Position | 2048 |
| Running degree | 360° (when 0~4095) |
| Resolution [deg/pulse] | 0.088°(360°/4096) |
| Rotating Direction | Clockwise(0→4095) |
| Feedback | Load(负载), Position(位置),Speed(工作速度), Input Voltage(输入电压),Current(工作电流),Temperature(工作温度) |
Resources and document status
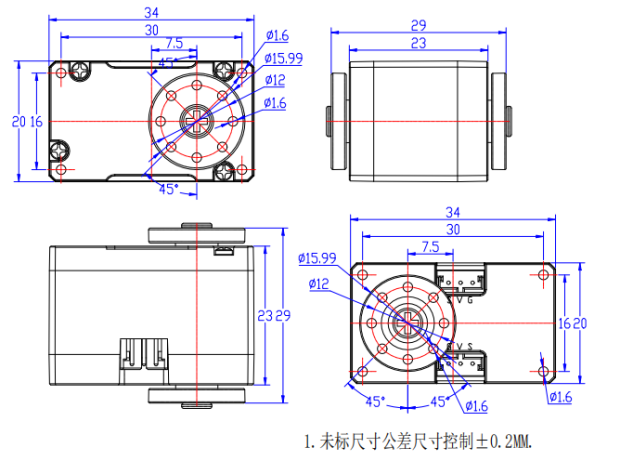
Local attachments are included in the model package; PDF specifications link to the manufacturer and are not bundled offline. Missing resources are not yet supplied; family guides do not verify model-specific settings.
| Resource | Status / file | Revision |
|---|---|---|
| Model datasheet | Not supplied | — |
| Connector and pinout | Not supplied | — |
| Model memory table / firmware notes | Not supplied | — |
| 2D mounting drawing | drawing.webp | — |
| STEP / 3D model | Not supplied | — |
| Model-tested example | Not supplied | — |
| Raw test data | Not supplied | — |
| Test record and conditions | Not supplied | — |
Package manifest · Request missing resources
For an offline ZIP with both languages and available attachments, see product-package export.
Request resources or report an issue
Use your existing FEETECH technical-support contact and include the full label/model suffix, firmware version (if known), and the document revision you are using.
- Software: controller/OS, SDK version or commit, adapter/interface, supply voltage, confirmed ID/baud rate (bus models only), minimal reproduction and logs.
- Mechanics: drawing/CAD revision, marked dimensions, required travel, horn/bracket, load and lever arm, duty cycle, and the point of interference.
- Missing files: name the exact item in the resource table (for example, this model's STEP and a dimensioned mounting drawing).
This package currently provides a specification summary and integration checklists. File availability does not imply that your firmware, load case or assembly has been validated.